|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
This class is the parameters parser for class ControlBoardRemapper. More...
#include <controlBoardRemapper/ControlBoardRemapper_ParamsParser.h>
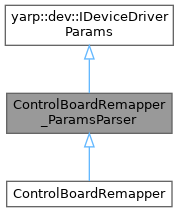
 Inheritance diagram for ControlBoardRemapper_ParamsParser:
Classes | |
| struct | parser_version_type |
Public Member Functions | |
| ControlBoardRemapper_ParamsParser () | |
| ~ControlBoardRemapper_ParamsParser () override=default | |
| bool | parseParams (const yarp::os::Searchable &config) override |
| Parse the DeviceDriver parameters. | |
| std::string | getDeviceClassName () const override |
| Get the name of the DeviceDriver class. | |
| std::string | getDeviceName () const override |
| Get the name of the device (i.e. | |
| std::string | getDocumentationOfDeviceParams () const override |
| Get the documentation of the DeviceDriver's parameters. | |
| std::vector< std::string > | getListOfParams () const override |
| Return a list of all params used by the device. | |
| bool | getParamValue (const std::string ¶mName, std::string ¶mValue) const override |
| Return the value (represented as a string) of the requested parameter. | |
| std::string | getConfiguration () const override |
| Return the configuration of the device. | |
| Public Member Functions inherited from yarp::dev::IDeviceDriverParams | |
| virtual | ~IDeviceDriverParams () |
Public Attributes | |
| const std::string | m_device_classname = {"ControlBoardRemapper"} |
| const std::string | m_device_name = {"controlboardremapper"} |
| bool | m_parser_is_strict = false |
| const parser_version_type | m_parser_version = {} |
| std::string | m_provided_configuration |
| const std::string | m_axesNames_defaultValue = {""} |
| const std::string | m_networkNames_defaultValue = {""} |
| const std::string | m_verbose_defaultValue = {"false"} |
| std::vector< std::string > | m_axesNames = {} |
| std::vector< std::string > | m_networkNames = {} |
| bool | m_verbose = {false} |
This class is the parameters parser for class ControlBoardRemapper.
These are the used parameters:
| Group name | Parameter name | Type | Units | Default Value | Required | Description | Notes |
|---|---|---|---|---|---|---|---|
| - | axesNames | vector<string> | - | - | 0 | Ordered list of the axes that are part of the remapped device. e.g.(/joint0 /joint1) | - |
| - | networkNames | vector<string> | - | - | 0 | List of the robot parts to be used in remapped device. e.g.(/partA /partB) | Deprecated. Requires additional params (here not specified). Cannot be used together with axesNames |
| - | verbose | bool | - | false | 0 | print additional output if enabled | - |
The device can be launched by yarpdev using one of the following examples (with and without all optional parameters):
Definition at line 43 of file ControlBoardRemapper_ParamsParser.h.
| ControlBoardRemapper_ParamsParser::ControlBoardRemapper_ParamsParser | ( | ) |
Definition at line 23 of file ControlBoardRemapper_ParamsParser.cpp.
|
overridedefault |
|
overridevirtual |
Return the configuration of the device.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 77 of file ControlBoardRemapper_ParamsParser.cpp.
|
inlineoverridevirtual |
Get the name of the DeviceDriver class.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 71 of file ControlBoardRemapper_ParamsParser.h.
|
inlineoverridevirtual |
Get the name of the device (i.e.
the plugin name).
Implements yarp::dev::IDeviceDriverParams.
Definition at line 72 of file ControlBoardRemapper_ParamsParser.h.
|
overridevirtual |
Get the documentation of the DeviceDriver's parameters.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 198 of file ControlBoardRemapper_ParamsParser.cpp.
|
overridevirtual |
Return a list of all params used by the device.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 28 of file ControlBoardRemapper_ParamsParser.cpp.
|
overridevirtual |
Return the value (represented as a string) of the requested parameter.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 38 of file ControlBoardRemapper_ParamsParser.cpp.
|
overridevirtual |
Parse the DeviceDriver parameters.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 87 of file ControlBoardRemapper_ParamsParser.cpp.
| std::vector<std::string> ControlBoardRemapper_ParamsParser::m_axesNames = {} |
Definition at line 66 of file ControlBoardRemapper_ParamsParser.h.
| const std::string ControlBoardRemapper_ParamsParser::m_axesNames_defaultValue = {""} |
Definition at line 62 of file ControlBoardRemapper_ParamsParser.h.
| const std::string ControlBoardRemapper_ParamsParser::m_device_classname = {"ControlBoardRemapper"} |
Definition at line 50 of file ControlBoardRemapper_ParamsParser.h.
| const std::string ControlBoardRemapper_ParamsParser::m_device_name = {"controlboardremapper"} |
Definition at line 51 of file ControlBoardRemapper_ParamsParser.h.
| std::vector<std::string> ControlBoardRemapper_ParamsParser::m_networkNames = {} |
Definition at line 67 of file ControlBoardRemapper_ParamsParser.h.
| const std::string ControlBoardRemapper_ParamsParser::m_networkNames_defaultValue = {""} |
Definition at line 63 of file ControlBoardRemapper_ParamsParser.h.
| bool ControlBoardRemapper_ParamsParser::m_parser_is_strict = false |
Definition at line 52 of file ControlBoardRemapper_ParamsParser.h.
| const parser_version_type ControlBoardRemapper_ParamsParser::m_parser_version = {} |
Definition at line 58 of file ControlBoardRemapper_ParamsParser.h.
| std::string ControlBoardRemapper_ParamsParser::m_provided_configuration |
Definition at line 60 of file ControlBoardRemapper_ParamsParser.h.
| bool ControlBoardRemapper_ParamsParser::m_verbose = {false} |
Definition at line 68 of file ControlBoardRemapper_ParamsParser.h.
| const std::string ControlBoardRemapper_ParamsParser::m_verbose_defaultValue = {"false"} |
Definition at line 64 of file ControlBoardRemapper_ParamsParser.h.
 1.9.8