|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
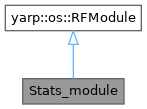
 Inheritance diagram for Stats_module:
Additional Inherited Members | |
| Public Member Functions inherited from yarp::os::RFModule | |
| RFModule () | |
| Constructor. | |
| virtual | ~RFModule () |
| Destructor. | |
| virtual int | runModule () |
| Calls updateModule() until that returns false. | |
| virtual int | runModule (yarp::os::ResourceFinder &rf) |
| Simple helper method to call configure() and then runModule(). | |
| virtual int | runModuleThreaded () |
| Calls updateModule() on a separate thread until that returns false. | |
| virtual int | runModuleThreaded (yarp::os::ResourceFinder &rf) |
| Simple helper method to call configure() and then runModule() on a separate thread. | |
| virtual int | getThreadKey () |
| return the Thread unique identifier | |
| virtual bool | respond (const Bottle &command, Bottle &reply) |
| Respond to a message. | |
| virtual bool | attach (yarp::os::Port &source) |
| Make any input from a Port object go to the respond() method. | |
| virtual bool | attach (yarp::os::RpcServer &source) |
| Make any input from an RpcServer object go to the respond() method. | |
| bool | attachTerminal () |
| Make any input from standard input (usually the keyboard) go to the respond() method. | |
| bool | detachTerminal () |
| Detach terminal. | |
| virtual bool | interruptModule () |
| Try to halt any ongoing operations by threads managed by the module. | |
| void | stopModule (bool wait=false) |
| Ask the module to stop. | |
| bool | isStopping () |
| Check if the module should stop. | |
| bool | joinModule (double seconds=-1) |
| The function returns when the thread execution has completed. | |
| std::string | getName (const std::string &subName="") |
| Return name of module, as set with setName(). | |
| void | setName (const char *name) |
| Set the name of the module. | |
| bool | safeRespond (const Bottle &command, Bottle &reply) |
| Wrapper around respond() that is guaranteed to process system messages. | |
 1.9.8