|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
This class is the parameters parser for class HapticDevice_nws_ros2. More...
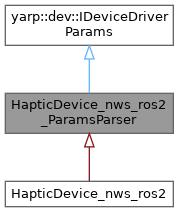
 Inheritance diagram for HapticDevice_nws_ros2_ParamsParser:
Classes | |
| struct | parser_version_type |
Public Member Functions | |
| HapticDevice_nws_ros2_ParamsParser () | |
| ~HapticDevice_nws_ros2_ParamsParser () override=default | |
| bool | parseParams (const yarp::os::Searchable &config) override |
| Parse the DeviceDriver parameters. | |
| std::string | getDeviceClassName () const override |
| Get the name of the DeviceDriver class. | |
| std::string | getDeviceName () const override |
| Get the name of the device (i.e. | |
| std::string | getDocumentationOfDeviceParams () const override |
| Get the documentation of the DeviceDriver's parameters. | |
| std::vector< std::string > | getListOfParams () const override |
| Return a list of all params used by the device. | |
| bool | getParamValue (const std::string ¶mName, std::string ¶mValue) const override |
| Return the value (represented as a string) of the requested parameter. | |
| std::string | getConfiguration () const override |
| Return the configuration of the device. | |
| Public Member Functions inherited from yarp::dev::IDeviceDriverParams | |
| virtual | ~IDeviceDriverParams () |
Public Attributes | |
| const std::string | m_device_classname = {"HapticDevice_nws_ros2"} |
| const std::string | m_device_name = {"hapticDevice_nws_ros2"} |
| bool | m_parser_is_strict = false |
| const parser_version_type | m_parser_version = {} |
| std::string | m_provided_configuration |
| const std::string | m_period_defaultValue = {"0.02"} |
| const std::string | m_node_name_defaultValue = {"hapticDevice_nws_ros2"} |
| const std::string | m_namespace_defaultValue = {""} |
| const std::string | m_topic_name_defaultValue = {""} |
| double | m_period = {0.02} |
| std::string | m_node_name = {"hapticDevice_nws_ros2"} |
| std::string | m_namespace = {} |
| std::string | m_topic_name = {} |
This class is the parameters parser for class HapticDevice_nws_ros2.
These are the used parameters:
| Group name | Parameter name | Type | Units | Default Value | Required | Description | Notes |
|---|---|---|---|---|---|---|---|
| - | period | double | s | 0.02 | 0 | refresh period | - |
| - | node_name | string | - | hapticDevice_nws_ros2 | 0 | name of node | - |
| - | namespace | string | - | - | 0 | optional namespace for ros2 node | - |
| - | topic_name | string | - | - | 0 | topic name where publish (not '/') | - |
The device can be launched by yarpdev using one of the following examples (with and without all optional parameters):
Definition at line 44 of file HapticDevice_nws_ros2_ParamsParser.h.
| HapticDevice_nws_ros2_ParamsParser::HapticDevice_nws_ros2_ParamsParser | ( | ) |
Definition at line 23 of file HapticDevice_nws_ros2_ParamsParser.cpp.
|
overridedefault |
|
overridevirtual |
Return the configuration of the device.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 68 of file HapticDevice_nws_ros2_ParamsParser.cpp.
|
inlineoverridevirtual |
Get the name of the DeviceDriver class.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 74 of file HapticDevice_nws_ros2_ParamsParser.h.
|
inlineoverridevirtual |
Get the name of the device (i.e.
the plugin name).
Implements yarp::dev::IDeviceDriverParams.
Definition at line 75 of file HapticDevice_nws_ros2_ParamsParser.h.
|
overridevirtual |
Get the documentation of the DeviceDriver's parameters.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 173 of file HapticDevice_nws_ros2_ParamsParser.cpp.
|
overridevirtual |
Return a list of all params used by the device.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 28 of file HapticDevice_nws_ros2_ParamsParser.cpp.
|
overridevirtual |
Return the value (represented as a string) of the requested parameter.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 39 of file HapticDevice_nws_ros2_ParamsParser.cpp.
|
overridevirtual |
Parse the DeviceDriver parameters.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 78 of file HapticDevice_nws_ros2_ParamsParser.cpp.
| const std::string HapticDevice_nws_ros2_ParamsParser::m_device_classname = {"HapticDevice_nws_ros2"} |
Definition at line 51 of file HapticDevice_nws_ros2_ParamsParser.h.
| const std::string HapticDevice_nws_ros2_ParamsParser::m_device_name = {"hapticDevice_nws_ros2"} |
Definition at line 52 of file HapticDevice_nws_ros2_ParamsParser.h.
| std::string HapticDevice_nws_ros2_ParamsParser::m_namespace = {} |
Definition at line 70 of file HapticDevice_nws_ros2_ParamsParser.h.
| const std::string HapticDevice_nws_ros2_ParamsParser::m_namespace_defaultValue = {""} |
Definition at line 65 of file HapticDevice_nws_ros2_ParamsParser.h.
| std::string HapticDevice_nws_ros2_ParamsParser::m_node_name = {"hapticDevice_nws_ros2"} |
Definition at line 69 of file HapticDevice_nws_ros2_ParamsParser.h.
| const std::string HapticDevice_nws_ros2_ParamsParser::m_node_name_defaultValue = {"hapticDevice_nws_ros2"} |
Definition at line 64 of file HapticDevice_nws_ros2_ParamsParser.h.
| bool HapticDevice_nws_ros2_ParamsParser::m_parser_is_strict = false |
Definition at line 53 of file HapticDevice_nws_ros2_ParamsParser.h.
| const parser_version_type HapticDevice_nws_ros2_ParamsParser::m_parser_version = {} |
Definition at line 59 of file HapticDevice_nws_ros2_ParamsParser.h.
| double HapticDevice_nws_ros2_ParamsParser::m_period = {0.02} |
Definition at line 68 of file HapticDevice_nws_ros2_ParamsParser.h.
| const std::string HapticDevice_nws_ros2_ParamsParser::m_period_defaultValue = {"0.02"} |
Definition at line 63 of file HapticDevice_nws_ros2_ParamsParser.h.
| std::string HapticDevice_nws_ros2_ParamsParser::m_provided_configuration |
Definition at line 61 of file HapticDevice_nws_ros2_ParamsParser.h.
| std::string HapticDevice_nws_ros2_ParamsParser::m_topic_name = {} |
Definition at line 71 of file HapticDevice_nws_ros2_ParamsParser.h.
| const std::string HapticDevice_nws_ros2_ParamsParser::m_topic_name_defaultValue = {""} |
Definition at line 66 of file HapticDevice_nws_ros2_ParamsParser.h.
 1.9.8