|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
This class is the parameters parser for class xHandControlBoard. More...
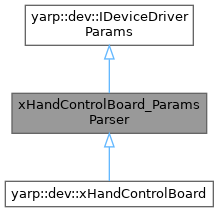
 Inheritance diagram for xHandControlBoard_ParamsParser:
Classes | |
| struct | parser_version_type |
Public Member Functions | |
| xHandControlBoard_ParamsParser () | |
| ~xHandControlBoard_ParamsParser () override=default | |
| bool | parseParams (const yarp::os::Searchable &config) override |
| Parse the DeviceDriver parameters. | |
| std::string | getDeviceClassName () const override |
| Get the name of the DeviceDriver class. | |
| std::string | getDeviceName () const override |
| Get the name of the device (i.e. | |
| std::string | getDocumentationOfDeviceParams () const override |
| Get the documentation of the DeviceDriver's parameters. | |
| std::vector< std::string > | getListOfParams () const override |
| Return a list of all params used by the device. | |
| bool | getParamValue (const std::string ¶mName, std::string ¶mValue) const override |
| Return the value (represented as a string) of the requested parameter. | |
| std::string | getConfiguration () const override |
| Return the configuration of the device. | |
| Public Member Functions inherited from yarp::dev::IDeviceDriverParams | |
| virtual | ~IDeviceDriverParams () |
Public Attributes | |
| const std::string | m_device_classname = {"xHandControlBoard"} |
| const std::string | m_device_name = {"xHandControlBoard"} |
| bool | m_parser_is_strict = false |
| const parser_version_type | m_parser_version = {} |
| std::string | m_provided_configuration |
| const std::string | m_connection_type_defaultValue = {"EtherCAT"} |
| const std::string | m_RS485_port_defaultValue = {"/dev/ttyUSB0"} |
| const std::string | m_RS485_baudrate_defaultValue = {"3000000"} |
| const std::string | m_ETHERCAT_eth_ifname_defaultValue = {""} |
| const std::string | m_PID_kp_defaultValue = {"225"} |
| const std::string | m_PID_ki_defaultValue = {"0"} |
| const std::string | m_PID_kd_defaultValue = {"12000"} |
| const std::string | m_TORQUE_tor_max_defaultValue = {"350"} |
| const std::string | m_MODE_mode_defaultValue = {"3"} |
| const std::string | m_LIMITS_jntPosMin_defaultValue = {"(0.0 -60.0 -0.0 -5.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0)"} |
| const std::string | m_LIMITS_jntPosMax_defaultValue = {"(90.0 90.0 90.0 17.0 110.0 110.0 110.0 110.0 110.0 110.0 110.0 110.0)"} |
| const std::string | m_LIMITS_jntVelMin_defaultValue = {"(0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0)"} |
| const std::string | m_LIMITS_jntVelMax_defaultValue = {"(100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0)"} |
| const std::string | m_GENERAL_AxisName_defaultValue = {"(a a a a a a a a a a a a)"} |
| const std::string | m_GENERAL_AxisType_defaultValue = {"(a a a a a a a a a a a a)"} |
| const std::string | m_GENERAL_AxisMap_defaultValue = {"(0 0 0 0 0 0 0 0 0 0 0 0)"} |
| std::string | m_connection_type = {"EtherCAT"} |
| std::string | m_RS485_port = {"/dev/ttyUSB0"} |
| int | m_RS485_baudrate = {3000000} |
| std::string | m_ETHERCAT_eth_ifname = {} |
| int | m_PID_kp = {225} |
| int | m_PID_ki = {0} |
| int | m_PID_kd = {12000} |
| int | m_TORQUE_tor_max = {350} |
| int | m_MODE_mode = {3} |
| std::vector< double > | m_LIMITS_jntPosMin = { } |
| std::vector< double > | m_LIMITS_jntPosMax = { } |
| std::vector< double > | m_LIMITS_jntVelMin = { } |
| std::vector< double > | m_LIMITS_jntVelMax = { } |
| std::vector< std::string > | m_GENERAL_AxisName = { } |
| std::vector< std::string > | m_GENERAL_AxisType = { } |
| std::vector< int > | m_GENERAL_AxisMap = { } |
This class is the parameters parser for class xHandControlBoard.
These are the used parameters:
| Group name | Parameter name | Type | Units | Default Value | Required | Description | Notes |
|---|---|---|---|---|---|---|---|
| - | connection_type | string | - | EtherCAT | 1 | Specify the connection type | Can be either "RS485" (USB) or "EtherCAT" (ethernet) |
| RS485 | port | string | - | /dev/ttyUSB0 | 0 | Specify the port to use for the serial connection | Necessary only if using "RS485" |
| RS485 | baudrate | int | - | 3000000 | 0 | Specify the baudrate for the serial connection | Necessary only if using "RS485" |
| ETHERCAT | eth_ifname | string | - | - | 0 | Specify the interface name for the ethercat connection | Necessary only if using "EtherCAT" |
| PID | kp | int | - | 225 | 0 | Finger motors P gain | - |
| PID | ki | int | - | 0 | 0 | Finger motors I gain | - |
| PID | kd | int | - | 12000 | 0 | Finger motors D gain | - |
| TORQUE | tor_max | int | - | 350 | 0 | Note: 350 is the value from their ethercat_test | - |
| MODE | mode | int | - | 3 | 0 | Powerless = 0; Powerfull = 3; Check the manual for others | - |
| LIMITS | jntPosMin | vector<double> | deg | (0.0 -60.0 -0.0 -5.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0) | 0 | - | - |
| LIMITS | jntPosMax | vector<double> | deg | (90.0 90.0 90.0 17.0 110.0 110.0 110.0 110.0 110.0 110.0 110.0 110.0) | 0 | - | - |
| LIMITS | jntVelMin | vector<double> | deg/s | (0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0) | 0 | - | - |
| LIMITS | jntVelMax | vector<double> | deg/s | (100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0) | 0 | - | - |
| GENERAL | AxisName | vector<string> | - | (a a a a a a a a a a a a) | 0 | - | - |
| GENERAL | AxisType | vector<string> | - | (a a a a a a a a a a a a) | 0 | - | - |
| GENERAL | AxisMap | vector<int> | - | (0 0 0 0 0 0 0 0 0 0 0 0) | 0 | - | - |
The device can be launched by yarpdev using one of the following examples (with and without all optional parameters):
Definition at line 56 of file xHandControlBoard_ParamsParser.h.
| xHandControlBoard_ParamsParser::xHandControlBoard_ParamsParser | ( | ) |
Definition at line 23 of file xHandControlBoard_ParamsParser.cpp.
|
overridedefault |
|
overridevirtual |
Return the configuration of the device.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 266 of file xHandControlBoard_ParamsParser.cpp.
|
inlineoverridevirtual |
Get the name of the DeviceDriver class.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 110 of file xHandControlBoard_ParamsParser.h.
|
inlineoverridevirtual |
Get the name of the device (i.e.
the plugin name).
Implements yarp::dev::IDeviceDriverParams.
Definition at line 111 of file xHandControlBoard_ParamsParser.h.
|
overridevirtual |
Get the documentation of the DeviceDriver's parameters.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 676 of file xHandControlBoard_ParamsParser.cpp.
|
overridevirtual |
Return a list of all params used by the device.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 161 of file xHandControlBoard_ParamsParser.cpp.
|
overridevirtual |
Return the value (represented as a string) of the requested parameter.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 184 of file xHandControlBoard_ParamsParser.cpp.
|
overridevirtual |
Parse the DeviceDriver parameters.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 276 of file xHandControlBoard_ParamsParser.cpp.
| std::string xHandControlBoard_ParamsParser::m_connection_type = {"EtherCAT"} |
Definition at line 92 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_connection_type_defaultValue = {"EtherCAT"} |
Definition at line 75 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_device_classname = {"xHandControlBoard"} |
Definition at line 63 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_device_name = {"xHandControlBoard"} |
Definition at line 64 of file xHandControlBoard_ParamsParser.h.
| std::string xHandControlBoard_ParamsParser::m_ETHERCAT_eth_ifname = {} |
Definition at line 95 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_ETHERCAT_eth_ifname_defaultValue = {""} |
Definition at line 78 of file xHandControlBoard_ParamsParser.h.
| std::vector<int> xHandControlBoard_ParamsParser::m_GENERAL_AxisMap = { } |
Definition at line 107 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_GENERAL_AxisMap_defaultValue = {"(0 0 0 0 0 0 0 0 0 0 0 0)"} |
Definition at line 90 of file xHandControlBoard_ParamsParser.h.
| std::vector<std::string> xHandControlBoard_ParamsParser::m_GENERAL_AxisName = { } |
Definition at line 105 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_GENERAL_AxisName_defaultValue = {"(a a a a a a a a a a a a)"} |
Definition at line 88 of file xHandControlBoard_ParamsParser.h.
| std::vector<std::string> xHandControlBoard_ParamsParser::m_GENERAL_AxisType = { } |
Definition at line 106 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_GENERAL_AxisType_defaultValue = {"(a a a a a a a a a a a a)"} |
Definition at line 89 of file xHandControlBoard_ParamsParser.h.
| std::vector<double> xHandControlBoard_ParamsParser::m_LIMITS_jntPosMax = { } |
Definition at line 102 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_LIMITS_jntPosMax_defaultValue = {"(90.0 90.0 90.0 17.0 110.0 110.0 110.0 110.0 110.0 110.0 110.0 110.0)"} |
Definition at line 85 of file xHandControlBoard_ParamsParser.h.
| std::vector<double> xHandControlBoard_ParamsParser::m_LIMITS_jntPosMin = { } |
Definition at line 101 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_LIMITS_jntPosMin_defaultValue = {"(0.0 -60.0 -0.0 -5.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0)"} |
Definition at line 84 of file xHandControlBoard_ParamsParser.h.
| std::vector<double> xHandControlBoard_ParamsParser::m_LIMITS_jntVelMax = { } |
Definition at line 104 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_LIMITS_jntVelMax_defaultValue = {"(100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0 100.0)"} |
Definition at line 87 of file xHandControlBoard_ParamsParser.h.
| std::vector<double> xHandControlBoard_ParamsParser::m_LIMITS_jntVelMin = { } |
Definition at line 103 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_LIMITS_jntVelMin_defaultValue = {"(0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0 0.0)"} |
Definition at line 86 of file xHandControlBoard_ParamsParser.h.
| int xHandControlBoard_ParamsParser::m_MODE_mode = {3} |
Definition at line 100 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_MODE_mode_defaultValue = {"3"} |
Definition at line 83 of file xHandControlBoard_ParamsParser.h.
| bool xHandControlBoard_ParamsParser::m_parser_is_strict = false |
Definition at line 65 of file xHandControlBoard_ParamsParser.h.
| const parser_version_type xHandControlBoard_ParamsParser::m_parser_version = {} |
Definition at line 71 of file xHandControlBoard_ParamsParser.h.
| int xHandControlBoard_ParamsParser::m_PID_kd = {12000} |
Definition at line 98 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_PID_kd_defaultValue = {"12000"} |
Definition at line 81 of file xHandControlBoard_ParamsParser.h.
| int xHandControlBoard_ParamsParser::m_PID_ki = {0} |
Definition at line 97 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_PID_ki_defaultValue = {"0"} |
Definition at line 80 of file xHandControlBoard_ParamsParser.h.
| int xHandControlBoard_ParamsParser::m_PID_kp = {225} |
Definition at line 96 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_PID_kp_defaultValue = {"225"} |
Definition at line 79 of file xHandControlBoard_ParamsParser.h.
| std::string xHandControlBoard_ParamsParser::m_provided_configuration |
Definition at line 73 of file xHandControlBoard_ParamsParser.h.
| int xHandControlBoard_ParamsParser::m_RS485_baudrate = {3000000} |
Definition at line 94 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_RS485_baudrate_defaultValue = {"3000000"} |
Definition at line 77 of file xHandControlBoard_ParamsParser.h.
| std::string xHandControlBoard_ParamsParser::m_RS485_port = {"/dev/ttyUSB0"} |
Definition at line 93 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_RS485_port_defaultValue = {"/dev/ttyUSB0"} |
Definition at line 76 of file xHandControlBoard_ParamsParser.h.
| int xHandControlBoard_ParamsParser::m_TORQUE_tor_max = {350} |
Definition at line 99 of file xHandControlBoard_ParamsParser.h.
| const std::string xHandControlBoard_ParamsParser::m_TORQUE_tor_max_defaultValue = {"350"} |
Definition at line 82 of file xHandControlBoard_ParamsParser.h.
 1.9.8