|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
ISimulatedWorld Interface. More...
#include <yarp/dev/ISimulatedWorld.h>
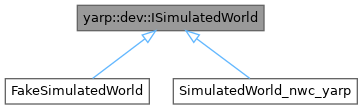
 Inheritance diagram for yarp::dev::ISimulatedWorld:
Public Member Functions | |
| virtual | ~ISimulatedWorld () |
| Destructor. | |
| virtual yarp::dev::ReturnValue | makeSphere (std::string id, double radius, yarp::sig::Pose6D pose, yarp::sig::ColorRGB color, std::string frame_name="", bool gravity_enable=0, bool collision_enable=1)=0 |
| Make a sphere. | |
| virtual yarp::dev::ReturnValue | makeBox (std::string id, double width, double height, double thickness, yarp::sig::Pose6D pose, yarp::sig::ColorRGB color, std::string frame_name="", bool gravity_enable=0, bool collision_enable=1)=0 |
| Make a box. | |
| virtual yarp::dev::ReturnValue | makeCylinder (std::string id, double radius, double length, yarp::sig::Pose6D pose, yarp::sig::ColorRGB color, std::string frame_name="", bool gravity_enable=0, bool collision_enable=1)=0 |
| Make a cylinder. | |
| virtual yarp::dev::ReturnValue | makeFrame (std::string id, double size, yarp::sig::Pose6D pose, yarp::sig::ColorRGB color, std::string frame_name="", bool gravity_enable=0, bool collision_enable=1)=0 |
| Make a reference frame (a 3D model with 3 arrows representing the axes) | |
| virtual yarp::dev::ReturnValue | makeModel (std::string id, std::string filename, yarp::sig::Pose6D pose, std::string frame_name="", bool gravity_enable=0, bool collision_enable=1)=0 |
| Create a model from a file. | |
| virtual yarp::dev::ReturnValue | makeActor (std::string id, std::string skin_filename, std::string animation_filename, yarp::sig::Pose6D pose)=0 |
| Create an actor. | |
| virtual yarp::dev::ReturnValue | changeColor (std::string id, yarp::sig::ColorRGB color)=0 |
| Change the color of an object. | |
| virtual yarp::dev::ReturnValue | setPose (std::string id, yarp::sig::Pose6D pose, std::string frame_name="")=0 |
| Set new object pose. | |
| virtual yarp::dev::ReturnValue | enableGravity (std::string id, bool enable)=0 |
| Enable/disables gravity for an object. | |
| virtual yarp::dev::ReturnValue | enableCollision (std::string id, bool enable)=0 |
| Enable/disables collision detection for an object. | |
| virtual yarp::dev::ReturnValue | getPose (std::string id, yarp::sig::Pose6D &pose, std::string frame_name="")=0 |
| Get object pose. | |
| virtual yarp::dev::ReturnValue | deleteObject (std::string id)=0 |
| Delete an object. | |
| virtual yarp::dev::ReturnValue | deleteAll ()=0 |
| Delete all objects in the world. | |
| virtual yarp::dev::ReturnValue | getList (std::vector< std::string > &names)=0 |
| List id of all objects that have been added to the world. | |
| virtual yarp::dev::ReturnValue | attach (std::string id, std::string link_name)=0 |
| Attach an object to a link of another object. | |
| virtual yarp::dev::ReturnValue | detach (std::string id)=0 |
| Detach a previously attached object. | |
| virtual yarp::dev::ReturnValue | rename (std::string old_name, std::string new_name)=0 |
| Change the names of an object. | |
ISimulatedWorld Interface.
Definition at line 27 of file ISimulatedWorld.h.
|
virtualdefault |
Destructor.
|
pure virtual |
Attach an object to a link of another object.
| id | string that identifies object in gazebo |
| link_name | name of a link |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Change the color of an object.
| id | object id |
| color | the color of the frame |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Delete all objects in the world.
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Delete an object.
| id | string that identifies object in gazebo |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Detach a previously attached object.
| id | string that identifies object in gazebo |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Enable/disables collision detection for an object.
| id | object id |
| enable | 1 to enable collision detection, 0 otherwise |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Enable/disables gravity for an object.
| id | object id |
| enable | 1 to enable gravity, 0 otherwise |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
List id of all objects that have been added to the world.
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Get object pose.
| id | object id |
| frame_name | (optional) is specified, the pose will be relative to the specified fully scoped frame (e.g. MODEL_ID::FRAME_ID). Otherwise, world it will be used. |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Create an actor.
| id | the name of the object to create |
| skin_filename | string that specifies the name of the model to load |
| animation_filename | string that specifies the name of the animation to load (e.g. walking, running, etc.) |
| pose | the initial pose of the object [m] |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Make a box.
| id | the name of the object to create |
| width | box width [m] |
| height | box height[m] |
| thickness | box thickness [m] |
| pose | the pose of the box [m] |
| color | the color of the box |
| frame_name | (optional) is specified, the pose will be relative to the specified fully scoped frame (e.g. MODEL_ID::FRAME_ID). Otherwise, world it will be used. |
| gravity_enable | (optional) enables gravity (default false) |
| collision_enable | (optional) enables collision (default true) |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Make a cylinder.
| id | the name of the object to create |
| radius | the radius of the cylinder [m] |
| length | the length of the cylinder [m] |
| pose | the pose of the cylinder [m] |
| color | the color of the cylinder |
| frame_name | (optional) is specified, the pose will be relative to the specified fully scoped frame (e.g. MODEL_ID::FRAME_ID). Otherwise, world it will be used. |
| object_name | (optional) assigns a name to the object. |
| gravity_enable | (optional) enables gravity (default false) |
| collision_enable | (optional) enables collision (default true) |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Make a reference frame (a 3D model with 3 arrows representing the axes)
| id | the name of the object to create |
| size | the size of the frame [m] |
| pose | the pose of the frame [m] |
| color | the color of the frame |
| frame_name | (optional) is specified, the pose will be relative to the specified fully scoped frame (e.g. MODEL_ID::FRAME_ID). Otherwise, world it will be used. |
| object_name | (optional) assigns a name to the object. |
| gravity_enable | (optional) enables gravity (default false) |
| collision_enable | (optional) enables collision (default true) |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Create a model from a file.
| id | the name of the object to create |
| filename | string that specifies the name of the model to load |
| pose | the initial pose of the object [m] |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Make a sphere.
| id | the name of the object to create |
| radius | the radius of the sphere [m] |
| pose | the pose of the sphere [m] |
| color | the color of the sphere |
| frame_name | (optional) is specified, the pose will be relative to the specified fully scoped frame (e.g. MODEL_ID::FRAME_ID). Otherwise, world it will be used. |
| gravity_enable | (optional) enables gravity (default false) |
| collision_enable | (optional) enables collision (default true) |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Change the names of an object.
| old_name | string that identifies object in gazebo |
| new_name | string that will be used as new name |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
|
pure virtual |
Set new object pose.
| id | object id |
| pose | new pose |
| frame_name | (optional) is specified, the pose will be relative to the specified fully scoped frame (e.g. MODEL_ID::FRAME_ID). Otherwise, world it will be used. |
Implemented in FakeSimulatedWorld, and SimulatedWorld_nwc_yarp.
 1.9.8