|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
SerialServoBoard: Documentation to be added
More...
#include <SerialServoBoard/SerialServoBoard.h>
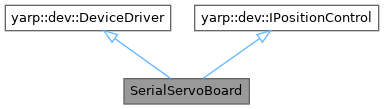
 Inheritance diagram for SerialServoBoard:
Public Member Functions | |
| yarp::dev::ReturnValue | getAxes (size_t &ax) override |
| Get the number of controlled axes. | |
| yarp::dev::ReturnValue | positionMove (int j, double ref) override |
| Set new reference point for a single axis. | |
| yarp::dev::ReturnValue | positionMove (const double *refs) override |
| Set new reference point for all axes. | |
| yarp::dev::ReturnValue | relativeMove (int j, double delta) override |
| Set relative position. | |
| yarp::dev::ReturnValue | relativeMove (const double *deltas) override |
| Set relative position, all joints. | |
| yarp::dev::ReturnValue | checkMotionDone (int j, bool &flag) override |
| Check if the current trajectory is terminated. | |
| yarp::dev::ReturnValue | checkMotionDone (bool &flag) override |
| Check if the current trajectory is terminated. | |
| yarp::dev::ReturnValue | setTrajSpeed (int j, double sp) override |
| Set reference speed for a joint, this is the speed used during the interpolation of the trajectory. | |
| yarp::dev::ReturnValue | setTrajSpeeds (const double *spds) override |
| Set reference speed on all joints. | |
| yarp::dev::ReturnValue | setTrajAcceleration (int j, double acc) override |
| Set reference acceleration for a joint. | |
| yarp::dev::ReturnValue | setTrajAccelerations (const double *accs) override |
| Set reference acceleration on all joints. | |
| yarp::dev::ReturnValue | getTrajSpeed (int j, double *ref) override |
| Get reference speed for a joint. | |
| yarp::dev::ReturnValue | getTrajSpeeds (double *spds) override |
| Get reference speed of all joints. | |
| yarp::dev::ReturnValue | getTrajAcceleration (int j, double *acc) override |
| Get reference acceleration for a joint. | |
| yarp::dev::ReturnValue | getTrajAccelerations (double *accs) override |
| Get reference acceleration of all joints. | |
| yarp::dev::ReturnValue | stop (int j) override |
| Stop motion, single joint. | |
| yarp::dev::ReturnValue | stop () override |
| Stop motion, multiple joints. | |
| yarp::dev::ReturnValue | positionMove (const int n_joint, const int *joints, const double *refs) override |
| Set new reference point for a subset of joints. | |
| yarp::dev::ReturnValue | relativeMove (const int n_joint, const int *joints, const double *deltas) override |
| Set relative position for a subset of joints. | |
| yarp::dev::ReturnValue | checkMotionDone (const std::vector< int > &joints, bool &flag) override |
| Check if the current trajectory is terminated. | |
| yarp::dev::ReturnValue | setTrajSpeeds (const int n_joint, const int *joints, const double *spds) override |
| Set reference speed on all joints. | |
| yarp::dev::ReturnValue | setTrajAccelerations (const int n_joint, const int *joints, const double *accs) override |
| Set reference acceleration on all joints. | |
| yarp::dev::ReturnValue | getTrajSpeeds (const int n_joint, const int *joints, double *spds) override |
| Get reference speed of all joints. | |
| yarp::dev::ReturnValue | getTrajAccelerations (const int n_joint, const int *joints, double *accs) override |
| Get reference acceleration for a joint. | |
| yarp::dev::ReturnValue | stop (const int n_joint, const int *joints) override |
| Stop motion for subset of joints. | |
| yarp::dev::ReturnValue | getTargetPosition (const int, double *) |
| Get the last position reference for the specified axis. | |
| yarp::dev::ReturnValue | getTargetPositions (double *) |
| Get the last position reference for all axes. | |
| yarp::dev::ReturnValue | getTargetPositions (const int, const int *, double *) |
| Get the last position reference for the specified group of axes. | |
| bool | open (Searchable &config) override |
| Open the DeviceDriver. | |
| bool | close () override |
| Close the DeviceDriver. | |
| Public Member Functions inherited from yarp::dev::DeviceDriver | |
| DeviceDriver () | |
| DeviceDriver (const DeviceDriver &other)=delete | |
| DeviceDriver (DeviceDriver &&other) noexcept=delete | |
| DeviceDriver & | operator= (const DeviceDriver &other)=delete |
| DeviceDriver & | operator= (DeviceDriver &&other) noexcept=delete |
| virtual | ~DeviceDriver () |
| virtual std::string | id () const |
| Return the id assigned to the PolyDriver. | |
| virtual void | setId (const std::string &id) |
| Set the id for this device. | |
| template<class T > | |
| bool | view (T *&x) |
| Get an interface to the device driver. | |
| virtual DeviceDriver * | getImplementation () |
| Some drivers are bureaucrats, pointing at others. | |
| Public Member Functions inherited from yarp::dev::IPositionControl | |
| virtual | ~IPositionControl () |
| Destructor. | |
Public Attributes | |
| int | servoboard |
| ISerialDevice * | serial |
| PolyDriver | dd |
| bool(* | move )(int j, double ref, double *positions, double *speeds, ISerialDevice *serial) |
| double * | positions |
| double * | speeds |
SerialServoBoard: Documentation to be added
Definition at line 43 of file SerialServoBoard.h.
|
overridevirtual |
Check if the current trajectory is terminated.
Non blocking.
| flag | is a pointer to return value ("and" of all joints) |
Implements yarp::dev::IPositionControl.
Definition at line 180 of file SerialServoBoard.cpp.
|
overridevirtual |
Check if the current trajectory is terminated.
Non blocking.
| joints | array of joint numbers |
| flag | logical "and" of all set of joints |
Implements yarp::dev::IPositionControl.
Definition at line 267 of file SerialServoBoard.cpp.
|
overridevirtual |
Check if the current trajectory is terminated.
Non blocking.
| j | is the axis number |
| flag | is a pointer to return value |
Implements yarp::dev::IPositionControl.
Definition at line 172 of file SerialServoBoard.cpp.
|
overridevirtual |
Close the DeviceDriver.
Reimplemented from yarp::dev::DeviceDriver.
Definition at line 103 of file SerialServoBoard.cpp.
|
overridevirtual |
Get the number of controlled axes.
This command asks the number of controlled axes for the current physical interface.
| ax | pointer to storage |
Implements yarp::dev::IPositionControl.
Definition at line 114 of file SerialServoBoard.cpp.
|
virtual |
Get the last position reference for the specified axis.
This is the dual of PositionMove and shall return only values sent using IPositionControl interface. If other interfaces like IPositionDirect are implemented by the device, this call must ignore their values, i.e. this call must never return a reference sent using IPositionDirect::SetPosition
| ref | last reference sent using PositionMove functions |
Implements yarp::dev::IPositionControl.
Definition at line 292 of file SerialServoBoard.cpp.
|
virtual |
Get the last position reference for the specified group of axes.
This is the dual of PositionMove and shall return only values sent using IPositionControl interface. If other interfaces like IPositionDirect are implemented by the device, this call must ignore their values, i.e. this call must never return a reference sent using IPositionDirect::SetPosition
| ref | last reference sent using PositionMove functions |
Implements yarp::dev::IPositionControl.
Definition at line 302 of file SerialServoBoard.cpp.
|
virtual |
Get the last position reference for all axes.
This is the dual of PositionMove and shall return only values sent using IPositionControl interface. If other interfaces like IPositionDirect are implemented by the device, this call must ignore their values, i.e. this call must never return a reference sent using IPositionDirect::SetPosition
| ref | last reference sent using PositionMove functions |
Implements yarp::dev::IPositionControl.
Definition at line 297 of file SerialServoBoard.cpp.
|
overridevirtual |
Get reference acceleration for a joint.
Returns the acceleration used to generate the trajectory profile.
| j | joint number |
| acc | pointer to storage for the return value |
Implements yarp::dev::IPositionControl.
Definition at line 236 of file SerialServoBoard.cpp.
|
overridevirtual |
Get reference acceleration for a joint.
Returns the acceleration used to generate the trajectory profile.
| joints | pointer to the array of joint numbers |
| accs | pointer to the array that will store the acceleration values |
Implements yarp::dev::IPositionControl.
Definition at line 283 of file SerialServoBoard.cpp.
|
overridevirtual |
Get reference acceleration of all joints.
These are the values used during the interpolation of the trajectory.
| accs | pointer to the array that will store the acceleration values. |
Implements yarp::dev::IPositionControl.
Definition at line 242 of file SerialServoBoard.cpp.
|
overridevirtual |
Get reference speed for a joint.
Returns the speed used to generate the trajectory profile.
| j | joint number |
| ref | pointer to storage for the return value |
Implements yarp::dev::IPositionControl.
Definition at line 218 of file SerialServoBoard.cpp.
|
overridevirtual |
Get reference speed of all joints.
These are the values used during the interpolation of the trajectory.
| joints | pointer to the array of joint numbers |
| spds | pointer to the array that will store the speed values. |
Implements yarp::dev::IPositionControl.
Definition at line 279 of file SerialServoBoard.cpp.
|
overridevirtual |
Get reference speed of all joints.
These are the values used during the interpolation of the trajectory.
| spds | pointer to the array that will store the speed values. |
Implements yarp::dev::IPositionControl.
Definition at line 226 of file SerialServoBoard.cpp.
|
overridevirtual |
Open the DeviceDriver.
| config | is a list of parameters for the device. Which parameters are effective for your device can vary. If there is no example for your device, you can run the "yarpdev" program with the verbose flag set to probe what parameters the device is checking. If that fails too, you'll need to read the source code (please nag one of the yarp developers to add documentation for your device). |
Reimplemented from yarp::dev::DeviceDriver.
Definition at line 31 of file SerialServoBoard.cpp.
|
overridevirtual |
Set new reference point for all axes.
| refs | array, new reference points. |
Implements yarp::dev::IPositionControl.
Definition at line 144 of file SerialServoBoard.cpp.
|
overridevirtual |
Set new reference point for a subset of joints.
| joints | pointer to the array of joint numbers |
| refs | pointer to the array specifying the new reference points |
Implements yarp::dev::IPositionControl.
Definition at line 259 of file SerialServoBoard.cpp.
|
overridevirtual |
Set new reference point for a single axis.
| j | joint number |
| ref | specifies the new ref point |
Implements yarp::dev::IPositionControl.
Definition at line 134 of file SerialServoBoard.cpp.
|
overridevirtual |
Set relative position, all joints.
| deltas | pointer to the relative commands |
Implements yarp::dev::IPositionControl.
Definition at line 162 of file SerialServoBoard.cpp.
|
overridevirtual |
Set relative position for a subset of joints.
| joints | pointer to the array of joint numbers |
| deltas | pointer to the array of relative commands |
Implements yarp::dev::IPositionControl.
Definition at line 263 of file SerialServoBoard.cpp.
|
overridevirtual |
Set relative position.
The command is relative to the current position of the axis.
| j | joint axis number |
| delta | relative command |
Implements yarp::dev::IPositionControl.
Definition at line 154 of file SerialServoBoard.cpp.
|
overridevirtual |
Set reference acceleration for a joint.
This value is used during the trajectory generation.
| j | joint number |
| acc | acceleration value |
Implements yarp::dev::IPositionControl.
Definition at line 206 of file SerialServoBoard.cpp.
|
overridevirtual |
Set reference acceleration on all joints.
This is the value that is used during the generation of the trajectory.
| accs | pointer to the array of acceleration values |
Implements yarp::dev::IPositionControl.
Definition at line 212 of file SerialServoBoard.cpp.
|
overridevirtual |
Set reference acceleration on all joints.
This is the value that is used during the generation of the trajectory.
| joints | pointer to the array of joint numbers |
| accs | pointer to the array with acceleration values |
Implements yarp::dev::IPositionControl.
Definition at line 275 of file SerialServoBoard.cpp.
|
overridevirtual |
Set reference speed for a joint, this is the speed used during the interpolation of the trajectory.
| j | joint number |
| sp | speed value |
Implements yarp::dev::IPositionControl.
Definition at line 188 of file SerialServoBoard.cpp.
|
overridevirtual |
Set reference speed on all joints.
These values are used during the interpolation of the trajectory.
| spds | pointer to the array of speed values. |
Implements yarp::dev::IPositionControl.
Definition at line 196 of file SerialServoBoard.cpp.
|
overridevirtual |
Set reference speed on all joints.
These values are used during the interpolation of the trajectory.
| joints | pointer to the array of joint numbers |
| spds | pointer to the array with speed values. |
Implements yarp::dev::IPositionControl.
Definition at line 271 of file SerialServoBoard.cpp.
|
overridevirtual |
Stop motion, multiple joints.
Implements yarp::dev::IPositionControl.
Definition at line 254 of file SerialServoBoard.cpp.
|
overridevirtual |
Stop motion for subset of joints.
| joints | pointer to the array of joint numbers |
Implements yarp::dev::IPositionControl.
Definition at line 287 of file SerialServoBoard.cpp.
|
overridevirtual |
Stop motion, single joint.
| j | joint number |
Implements yarp::dev::IPositionControl.
Definition at line 248 of file SerialServoBoard.cpp.
| PolyDriver SerialServoBoard::dd |
Definition at line 50 of file SerialServoBoard.h.
| bool(* SerialServoBoard::move) (int j, double ref, double *positions, double *speeds, ISerialDevice *serial) |
Definition at line 52 of file SerialServoBoard.h.
| double* SerialServoBoard::positions |
Definition at line 54 of file SerialServoBoard.h.
| ISerialDevice* SerialServoBoard::serial |
Definition at line 48 of file SerialServoBoard.h.
| int SerialServoBoard::servoboard |
Definition at line 46 of file SerialServoBoard.h.
| double* SerialServoBoard::speeds |
Definition at line 55 of file SerialServoBoard.h.
 1.9.8