#include <yarp/dev/ImplementTorqueControl.h>
|
| | ImplementTorqueControl (yarp::dev::ITorqueControlRaw *y) |
| |
| virtual | ~ImplementTorqueControl () |
| | Destructor.
|
| |
| yarp::dev::ReturnValue | getAxes (size_t &ax) override |
| | Get the number of controlled axes.
|
| |
| yarp::dev::ReturnValue | getRefTorque (int j, double *) override |
| | Get the reference value of the torque for a given joint.
|
| |
| yarp::dev::ReturnValue | getRefTorques (double *t) override |
| | Get the reference value of the torque for all joints.
|
| |
| yarp::dev::ReturnValue | setRefTorques (const double *t) override |
| | Set the reference value of the torque for all joints.
|
| |
| yarp::dev::ReturnValue | setRefTorque (int j, double t) override |
| | Set the reference value of the torque for a given joint.
|
| |
| yarp::dev::ReturnValue | setRefTorques (const int n_joint, const int *joints, const double *t) override |
| | Set new torque reference for a subset of joints.
|
| |
| yarp::dev::ReturnValue | getTorques (double *t) override |
| | Get the value of the torque for all joints (this is the feedback if you have torque sensors).
|
| |
| yarp::dev::ReturnValue | getTorque (int j, double *t) override |
| | Get the value of the torque on a given joint (this is the feedback if you have a torque sensor).
|
| |
| yarp::dev::ReturnValue | setMotorTorqueParams (int j, const yarp::dev::MotorTorqueParameters params) override |
| | Set a subset of motor parameters (bemf, ktau etc) useful for torque control.
|
| |
| yarp::dev::ReturnValue | getMotorTorqueParams (int j, yarp::dev::MotorTorqueParameters *params) override |
| | Get a subset of motor parameters (bemf, ktau etc) useful for torque control.
|
| |
| yarp::dev::ReturnValue | getTorqueRange (int j, double *min, double *max) override |
| | Get the full scale of the torque sensor of a given joint.
|
| |
| yarp::dev::ReturnValue | getTorqueRanges (double *min, double *max) override |
| | Get the full scale of the torque sensors of all joints.
|
| |
| virtual | ~ITorqueControl () |
| | Destructor.
|
| |
Definition at line 23 of file ImplementTorqueControl.h.
◆ ImplementTorqueControl()
◆ ~ImplementTorqueControl()
| ImplementTorqueControl::~ImplementTorqueControl |
( |
| ) |
|
|
virtual |
◆ getAxes()
◆ getMotorTorqueParams()
Get a subset of motor parameters (bemf, ktau etc) useful for torque control.
- Parameters
-
| j | joint number |
| params | a struct containing the motor parameters to be retrieved |
- Returns
- true/false on success/failure
Implements yarp::dev::ITorqueControl.
Definition at line 100 of file ImplementTorqueControl.cpp.
◆ getRefTorque()
Get the reference value of the torque for a given joint.
This is NOT the feedback (see getTorque instead).
- Parameters
-
| j | joint number |
| t | the returned reference torque of joint j |
- Returns
- true/false on success/failure
Implements yarp::dev::ITorqueControl.
Definition at line 63 of file ImplementTorqueControl.cpp.
◆ getRefTorques()
Get the reference value of the torque for all joints.
This is NOT the feedback (see getTorques instead).
- Parameters
-
| t | pointer to the array of torque values |
- Returns
- true/false on success/failure
Implements yarp::dev::ITorqueControl.
Definition at line 128 of file ImplementTorqueControl.cpp.
◆ getTorque()
Get the value of the torque on a given joint (this is the feedback if you have a torque sensor).
- Parameters
-
| j | joint number |
| t | pointer to the result value |
- Returns
- true/false on success/failure
Implements yarp::dev::ITorqueControl.
Definition at line 189 of file ImplementTorqueControl.cpp.
◆ getTorqueRange()
Get the full scale of the torque sensor of a given joint.
- Parameters
-
| j | joint number |
| min | minimum torque of the joint j |
| max | maximum torque of the joint j |
- Returns
- true/false on success/failure
Implements yarp::dev::ITorqueControl.
Definition at line 213 of file ImplementTorqueControl.cpp.
◆ getTorqueRanges()
Get the full scale of the torque sensors of all joints.
- Parameters
-
| min | pointer to the array that will store minimum torques of the joints |
| max | pointer to the array that will store maximum torques of the joints |
- Returns
- true/false on success/failure
Implements yarp::dev::ITorqueControl.
Definition at line 200 of file ImplementTorqueControl.cpp.
◆ getTorques()
Get the value of the torque for all joints (this is the feedback if you have torque sensors).
- Parameters
-
| t | pointer to the array that will store the output |
- Returns
- true/false on success/failure
Implements yarp::dev::ITorqueControl.
Definition at line 161 of file ImplementTorqueControl.cpp.
◆ initialize()
Initialize the internal data and alloc memory.
- Parameters
-
| size | is the number of controlled axes the driver deals with. |
| amap | is a lookup table mapping axes onto physical drivers. |
| enc | is an array containing the encoder to angles conversion factors. |
| zos | is an array containing the zeros of the encoders. |
- Returns
- true if initialized succeeded, false if it wasn't executed, or assert.
Definition at line 29 of file ImplementTorqueControl.cpp.
◆ setMotorTorqueParams()
Set a subset of motor parameters (bemf, ktau etc) useful for torque control.
- Parameters
-
| j | joint number |
| params | a struct containing the motor parameters to be set |
- Returns
- true/false on success/failure
Implements yarp::dev::ITorqueControl.
Definition at line 78 of file ImplementTorqueControl.cpp.
◆ setRefTorque()
◆ setRefTorques() [1/2]
◆ setRefTorques() [2/2]
Set new torque reference for a subset of joints.
- Parameters
-
| joints | pointer to the array of joint numbers |
| refs | pointer to the array specifying the new torque reference |
- Returns
- true/false on success/failure
Implements yarp::dev::ITorqueControl.
Definition at line 172 of file ImplementTorqueControl.cpp.
◆ uninitialize()
| bool ImplementTorqueControl::uninitialize |
( |
| ) |
|
|
protected |
Clean up internal data and memory.
- Returns
- true if uninitialization is executed, false otherwise.
Definition at line 45 of file ImplementTorqueControl.cpp.
◆ m_buffer_doubles
| std::vector<double> yarp::dev::ImplementTorqueControl::m_buffer_doubles |
|
protected |
◆ m_buffer_doubles2
| std::vector<double> yarp::dev::ImplementTorqueControl::m_buffer_doubles2 |
|
protected |
◆ m_buffer_ints
| std::vector<int> yarp::dev::ImplementTorqueControl::m_buffer_ints |
|
protected |
◆ m_helper
| void* yarp::dev::ImplementTorqueControl::m_helper =nullptr |
|
protected |
◆ m_imp_mutex
| std::mutex yarp::dev::ImplementTorqueControl::m_imp_mutex |
|
protected |
◆ m_iraw
The documentation for this class was generated from the following files:


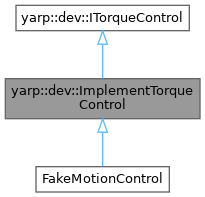
 Inheritance diagram for yarp::dev::ImplementTorqueControl:
 1.9.8