|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
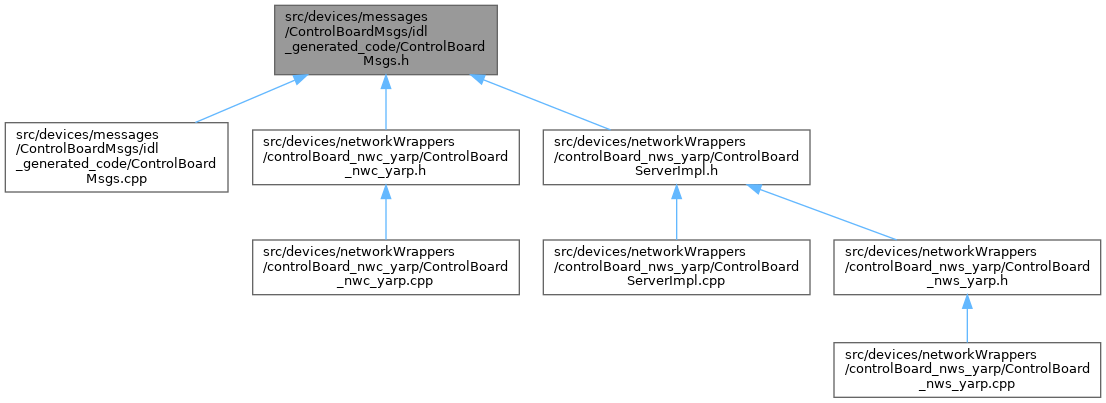
#include <yarp/os/Wire.h>#include <yarp/os/idl/WireTypes.h>#include <yarp/os/ApplicationNetworkProtocolVersion.h>#include <return_checkMotionDoneAll.h>#include <return_checkMotionDoneGroup.h>#include <return_checkMotionDoneOne.h>#include <return_getAmpStatusAll.h>#include <return_getAmpStatusOne.h>#include <return_getAutoBrakeEnabled.h>#include <return_getAvailableControlModes.h>#include <return_getAvailablePids.h>#include <return_getAxes.h>#include <return_getAxisName.h>#include <return_getCurrentAll.h>#include <return_getCurrentImpedanceLimit.h>#include <return_getCurrentOne.h>#include <return_getCurrentRangeAll.h>#include <return_getCurrentRangeOne.h>#include <return_getDeviceInterfaces.h>#include <return_getDutyCycleAll.h>#include <return_getDutyCycleOne.h>#include <return_getEncoderAccelerationAll.h>#include <return_getEncoderAccelerationOne.h>#include <return_getEncoderAll.h>#include <return_getEncoderOne.h>#include <return_getEncoderSpeedAll.h>#include <return_getEncoderSpeedOne.h>#include <return_getEncoderTimedAll.h>#include <return_getEncoderTimedOne.h>#include <return_getGearboxRatio.h>#include <return_getImpedance.h>#include <return_getImpedanceOffset.h>#include <return_getInteractionModeAll.h>#include <return_getInteractionModeGroup.h>#include <return_getInteractionModeOne.h>#include <return_getJointType.h>#include <return_getLastJointFault.h>#include <return_getMaxCurrent.h>#include <return_getMotorEncoderAccelerationAll.h>#include <return_getMotorEncoderAccelerationOne.h>#include <return_getMotorEncoderAll.h>#include <return_getMotorEncoderCountsPerRevolution.h>#include <return_getMotorEncoderOne.h>#include <return_getMotorEncoderSpeedAll.h>#include <return_getMotorEncoderSpeedOne.h>#include <return_getMotorEncoderTimedAll.h>#include <return_getMotorEncoderTimedOne.h>#include <return_getMotorTorqueParams.h>#include <return_getNominalCurrent.h>#include <return_getNumberOfMotorEncoders.h>#include <return_getNumberOfMotors.h>#include <return_getPWM.h>#include <return_getPWMLimit.h>#include <return_getPeakCurrent.h>#include <return_getPid.h>#include <return_getPidError.h>#include <return_getPidErrorLimit.h>#include <return_getPidErrorLimits.h>#include <return_getPidErrors.h>#include <return_getPidExtraInfo.h>#include <return_getPidExtraInfos.h>#include <return_getPidFeedforward.h>#include <return_getPidOffset.h>#include <return_getPidOutput.h>#include <return_getPidOutputs.h>#include <return_getPidReference.h>#include <return_getPidReferences.h>#include <return_getPids.h>#include <return_getPosLimits.h>#include <return_getPowerSupplyVoltage.h>#include <return_getRefCurrentAll.h>#include <return_getRefCurrentOne.h>#include <return_getRefDutyCycleAll.h>#include <return_getRefDutyCycleOne.h>#include <return_getRefPositionAll.h>#include <return_getRefPositionGroup.h>#include <return_getRefPositionOne.h>#include <return_getRefTorqueAll.h>#include <return_getRefTorqueGroup.h>#include <return_getRefTorqueOne.h>#include <return_getRefVelocityAll.h>#include <return_getRefVelocityGroup.h>#include <return_getRefVelocityOne.h>#include <return_getRemoteVariable.h>#include <return_getRemoteVariablesList.h>#include <return_getTargetPositionAll.h>#include <return_getTargetPositionGroup.h>#include <return_getTargetPositionOne.h>#include <return_getTargetVelocityAll.h>#include <return_getTargetVelocityGroup.h>#include <return_getTargetVelocityOne.h>#include <return_getTemperatureAll.h>#include <return_getTemperatureLimit.h>#include <return_getTemperatureOne.h>#include <return_getTorqueRangeAll.h>#include <return_getTorqueRangeOne.h>#include <return_getTrajAccelerationAll.h>#include <return_getTrajAccelerationGroup.h>#include <return_getTrajAccelerationOne.h>#include <return_getTrajSpeedOne.h>#include <return_getTrajSpeedsAll.h>#include <return_getTrajSpeedsGroup.h>#include <return_getVelLimits.h>#include <return_isCalibratorDevicePresent.h>#include <return_isJointBraked.h>#include <return_isPidEnabled.h>#include <yCalibrationParameters.h>#include <yMotorTorqueParameters.h>#include <yarp/dev/ControlBoardPid.h>#include <yarp/dev/IControlMode.h>#include <yarp/dev/IInteractionMode.h>#include <yarp/dev/PidEnums.h>#include <yarp/dev/ReturnValue.h>#include <yarp/os/Bottle.h> This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | ControlBoardMsgs |
 1.9.8