|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
#include <yarp/dev/ImplementEncodersTimed.h>
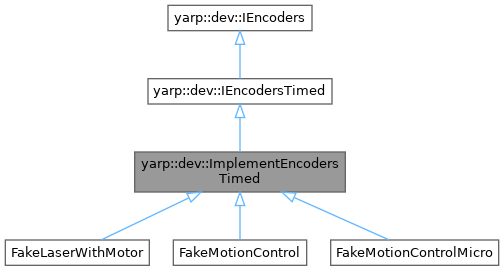
 Inheritance diagram for yarp::dev::ImplementEncodersTimed:
Public Member Functions | |
| ImplementEncodersTimed (yarp::dev::IEncodersTimedRaw *y) | |
| virtual | ~ImplementEncodersTimed () |
| yarp::dev::ReturnValue | getAxes (size_t &ax) override |
| Get the number of controlled axes. | |
| yarp::dev::ReturnValue | resetEncoder (int j) override |
| Reset encoder, single joint. | |
| yarp::dev::ReturnValue | resetEncoders () override |
| Reset encoders. | |
| yarp::dev::ReturnValue | setEncoder (int j, double val) override |
| Set the value of the encoder for a given joint. | |
| yarp::dev::ReturnValue | setEncoders (const double *vals) override |
| Set the value of all encoders. | |
| yarp::dev::ReturnValue | getEncoder (int j, double *v) override |
| Read the value of an encoder. | |
| yarp::dev::ReturnValue | getEncodersTimed (double *encs, double *time) override |
| Read the instantaneous acceleration of all axes. | |
| yarp::dev::ReturnValue | getEncoderTimed (int j, double *v, double *t) override |
| Read the instantaneous acceleration of all axes. | |
| yarp::dev::ReturnValue | getEncoders (double *encs) override |
| Read the position of all axes. | |
| yarp::dev::ReturnValue | getEncoderSpeed (int j, double *spds) override |
| Read the istantaneous speed of an axis. | |
| yarp::dev::ReturnValue | getEncoderSpeeds (double *spds) override |
| Read the instantaneous speed of all axes. | |
| yarp::dev::ReturnValue | getEncoderAcceleration (int j, double *spds) override |
| Read the instantaneous acceleration of an axis. | |
| yarp::dev::ReturnValue | getEncoderAccelerations (double *accs) override |
| Read the instantaneous acceleration of all axes. | |
| Public Member Functions inherited from yarp::dev::IEncodersTimed | |
| virtual | ~IEncodersTimed () |
| Destructor. | |
| Public Member Functions inherited from yarp::dev::IEncoders | |
| virtual | ~IEncoders () |
| Destructor. | |
Protected Member Functions | |
| bool | initialize (int size, const int *amap, const double *enc, const double *zos) |
| Initialize the internal data and alloc memory. | |
| bool | uninitialize () |
| Clean up internal data and memory. | |
Protected Attributes | |
| IEncodersTimedRaw * | m_iraw =nullptr |
| void * | m_helper =nullptr |
| std::vector< int > | m_buffer_ints |
| std::vector< double > | m_buffer_doubles |
| std::vector< double > | m_buffer_doubles2 |
| std::mutex | m_imp_mutex |
Definition at line 22 of file ImplementEncodersTimed.h.
| ImplementEncodersTimed::ImplementEncodersTimed | ( | yarp::dev::IEncodersTimedRaw * | y | ) |
Definition at line 22 of file ImplementEncodersTimed.cpp.
|
virtual |
Definition at line 27 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Get the number of controlled axes.
This command asks the number of controlled axes for the current physical interface.
Implements yarp::dev::IEncoders.
Definition at line 63 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Read the value of an encoder.
| j | encoder number |
| v | pointer to storage for the return value |
Implements yarp::dev::IEncoders.
Definition at line 113 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Read the instantaneous acceleration of an axis.
| j | axis number |
| spds | pointer to the array that will contain the output |
Implements yarp::dev::IEncoders.
Definition at line 173 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Read the instantaneous acceleration of all axes.
| accs | pointer to the array that will contain the output |
Implements yarp::dev::IEncoders.
Definition at line 192 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Read the position of all axes.
| encs | pointer to the array that will contain the output |
Implements yarp::dev::IEncoders.
Definition at line 132 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Read the istantaneous speed of an axis.
| j | axis number |
| sp | pointer to storage for the output |
Implements yarp::dev::IEncoders.
Definition at line 143 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Read the instantaneous speed of all axes.
| spds | pointer to storage for the output values |
Implements yarp::dev::IEncoders.
Definition at line 162 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Read the instantaneous acceleration of all axes.
| encs | pointer to the array that will contain the output |
| time | pointer to the array that will contain individual timestamps |
Implements yarp::dev::IEncodersTimed.
Definition at line 224 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Read the instantaneous acceleration of all axes.
| j | axis index |
| encs | encoder value (pointer to) |
| time | corresponding timestamp (pointer to) |
Implements yarp::dev::IEncodersTimed.
Definition at line 203 of file ImplementEncodersTimed.cpp.
|
protected |
Initialize the internal data and alloc memory.
| size | is the number of controlled axes the driver deals with. |
| amap | is a lookup table mapping axes onto physical drivers. |
| enc | is an array containing the encoder to angles conversion factors. |
| zos | is an array containing the zeros of the encoders. |
Definition at line 32 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Reset encoder, single joint.
Set the encoder value to zero
| j | encoder number |
Implements yarp::dev::IEncoders.
Definition at line 71 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Reset encoders.
Set the encoders value to zero
Implements yarp::dev::IEncoders.
Definition at line 82 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Set the value of the encoder for a given joint.
| j | encoder number |
| val | new value |
Implements yarp::dev::IEncoders.
Definition at line 89 of file ImplementEncodersTimed.cpp.
|
overridevirtual |
Set the value of all encoders.
| vals | pointer to the new values |
Implements yarp::dev::IEncoders.
Definition at line 102 of file ImplementEncodersTimed.cpp.
|
protected |
Clean up internal data and memory.
Definition at line 52 of file ImplementEncodersTimed.cpp.
|
protected |
Definition at line 28 of file ImplementEncodersTimed.h.
|
protected |
Definition at line 29 of file ImplementEncodersTimed.h.
|
protected |
Definition at line 27 of file ImplementEncodersTimed.h.
|
protected |
Definition at line 26 of file ImplementEncodersTimed.h.
|
protected |
Definition at line 30 of file ImplementEncodersTimed.h.
|
protected |
Definition at line 25 of file ImplementEncodersTimed.h.
 1.9.8