|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
fakeDepthCamera_mini: Documentation to be added
More...
#include <fake/fakeDepthCamera/FakeDepthCameraDriver_mini.h>
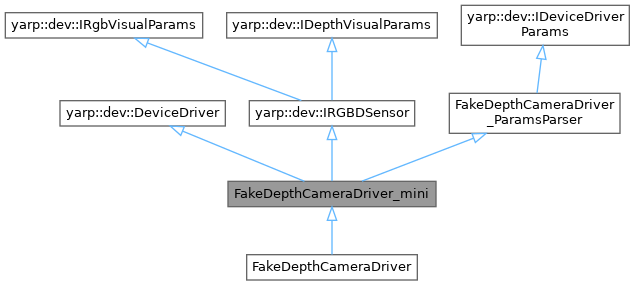
 Inheritance diagram for FakeDepthCameraDriver_mini:
Public Member Functions | |
| FakeDepthCameraDriver_mini () | |
| ~FakeDepthCameraDriver_mini () override | |
| bool | open (yarp::os::Searchable &config) override |
| Open the DeviceDriver. | |
| bool | close () override |
| Close the DeviceDriver. | |
| int | getRgbHeight () override |
| Return the height of each frame. | |
| int | getRgbWidth () override |
| Return the width of each frame. | |
| yarp::dev::ReturnValue | getRgbSupportedConfigurations (std::vector< yarp::dev::CameraConfig > &configurations) override |
| Get the possible configurations of the camera. | |
| yarp::dev::ReturnValue | getRgbResolution (int &width, int &height) override |
| Get the resolution of the rgb image from the camera. | |
| yarp::dev::ReturnValue | setRgbResolution (int width, int height) override |
| Set the resolution of the rgb image from the camera. | |
| yarp::dev::ReturnValue | getRgbFOV (double &horizontalFov, double &verticalFov) override |
| Get the field of view (FOV) of the rgb camera. | |
| yarp::dev::ReturnValue | setRgbFOV (double horizontalFov, double verticalFov) override |
| Set the field of view (FOV) of the rgb camera. | |
| yarp::dev::ReturnValue | getRgbMirroring (bool &mirror) override |
| Get the mirroring setting of the sensor. | |
| yarp::dev::ReturnValue | setRgbMirroring (bool mirror) override |
| Set the mirroring setting of the sensor. | |
| yarp::dev::ReturnValue | getRgbIntrinsicParam (yarp::sig::IntrinsicParams &intrinsic) override |
| Get the intrinsic parameters of the rgb camera. | |
| int | getDepthHeight () override |
| Return the height of each frame. | |
| int | getDepthWidth () override |
| Return the height of each frame. | |
| yarp::dev::ReturnValue | getDepthResolution (int &width, int &height) override |
| Get the resolution of the depth image from the camera. | |
| yarp::dev::ReturnValue | setDepthResolution (int width, int height) override |
| Set the resolution of the depth image from the camera. | |
| yarp::dev::ReturnValue | getDepthFOV (double &horizontalFov, double &verticalFov) override |
| Get the field of view (FOV) of the depth camera. | |
| yarp::dev::ReturnValue | setDepthFOV (double horizontalFov, double verticalFov) override |
| Set the field of view (FOV) of the depth camera. | |
| yarp::dev::ReturnValue | getDepthIntrinsicParam (yarp::sig::IntrinsicParams &intrinsic) override |
| Get the intrinsic parameters of the depth camera. | |
| yarp::dev::ReturnValue | getDepthAccuracy (double &accuracy) override |
| Get the minimum detectable variation in distance [meter]. | |
| yarp::dev::ReturnValue | setDepthAccuracy (double accuracy) override |
| Set the minimum detectable variation in distance [meter] when possible. | |
| yarp::dev::ReturnValue | getDepthClipPlanes (double &nearPlane, double &farPlane) override |
| Get the clipping planes of the sensor. | |
| yarp::dev::ReturnValue | setDepthClipPlanes (double nearPlane, double farPlane) override |
| Set the clipping planes of the sensor. | |
| yarp::dev::ReturnValue | getDepthMirroring (bool &mirror) override |
| Get the mirroring setting of the sensor. | |
| yarp::dev::ReturnValue | setDepthMirroring (bool mirror) override |
| Set the mirroring setting of the sensor. | |
| yarp::dev::ReturnValue | getExtrinsicParam (yarp::sig::Matrix &extrinsic) override |
| Get the extrinsic parameters from the device. | |
| yarp::dev::ReturnValue | getRgbImage (FlexImage &rgbImage, Stamp *timeStamp=nullptr) override |
| Get the rgb frame from the device. | |
| yarp::dev::ReturnValue | getDepthImage (depthImage &depthImage, Stamp *timeStamp=nullptr) override |
| yarp::dev::ReturnValue | getImages (FlexImage &colorFrame, depthImage &depthFrame, Stamp *colorStamp=nullptr, Stamp *depthStamp=nullptr) override |
| yarp::dev::ReturnValue | getSensorStatus (RGBDSensor_status &status) override |
| yarp::dev::ReturnValue | getLastErrorMsg (std::string &mesg, Stamp *timeStamp=nullptr) override |
| Return an error message in case of error. | |
| Public Member Functions inherited from yarp::dev::DeviceDriver | |
| DeviceDriver () | |
| DeviceDriver (const DeviceDriver &other)=delete | |
| DeviceDriver (DeviceDriver &&other) noexcept=delete | |
| DeviceDriver & | operator= (const DeviceDriver &other)=delete |
| DeviceDriver & | operator= (DeviceDriver &&other) noexcept=delete |
| virtual | ~DeviceDriver () |
| virtual std::string | id () const |
| Return the id assigned to the PolyDriver. | |
| virtual void | setId (const std::string &id) |
| Set the id for this device. | |
| template<class T > | |
| bool | view (T *&x) |
| Get an interface to the device driver. | |
| virtual DeviceDriver * | getImplementation () |
| Some drivers are bureaucrats, pointing at others. | |
| Public Member Functions inherited from yarp::dev::IRGBDSensor | |
| virtual | ~IRGBDSensor () |
| virtual yarp::dev::ReturnValue | getDepthImage (yarp::sig::ImageOf< yarp::sig::PixelFloat > &depthImage, yarp::os::Stamp *timeStamp=nullptr)=0 |
| Get the depth frame from the device. | |
| virtual yarp::dev::ReturnValue | getImages (yarp::sig::FlexImage &colorFrame, yarp::sig::ImageOf< yarp::sig::PixelFloat > &depthFrame, yarp::os::Stamp *colorStamp=nullptr, yarp::os::Stamp *depthStamp=nullptr)=0 |
| Get the both the color and depth frame in a single call. | |
| virtual yarp::dev::ReturnValue | getSensorStatus (RGBDSensor_status &status)=0 |
| Get the current status of the sensor, using enum type. | |
| Public Member Functions inherited from yarp::dev::IRgbVisualParams | |
| virtual | ~IRgbVisualParams () |
| Public Member Functions inherited from yarp::dev::IDepthVisualParams | |
| virtual | ~IDepthVisualParams () |
| Public Member Functions inherited from FakeDepthCameraDriver_ParamsParser | |
| FakeDepthCameraDriver_ParamsParser () | |
| ~FakeDepthCameraDriver_ParamsParser () override=default | |
| bool | parseParams (const yarp::os::Searchable &config) override |
| Parse the DeviceDriver parameters. | |
| std::string | getDeviceClassName () const override |
| Get the name of the DeviceDriver class. | |
| std::string | getDeviceName () const override |
| Get the name of the device (i.e. | |
| std::string | getDocumentationOfDeviceParams () const override |
| Get the documentation of the DeviceDriver's parameters. | |
| std::vector< std::string > | getListOfParams () const override |
| Return a list of all params used by the device. | |
| bool | getParamValue (const std::string ¶mName, std::string ¶mValue) const override |
| Return the value (represented as a string) of the requested parameter. | |
| std::string | getConfiguration () const override |
| Return the configuration of the device. | |
| Public Member Functions inherited from yarp::dev::IDeviceDriverParams | |
| virtual | ~IDeviceDriverParams () |
Protected Types | |
| typedef yarp::sig::ImageOf< yarp::sig::PixelFloat > | depthImage |
| typedef yarp::os::Stamp | Stamp |
| typedef yarp::os::Property | Property |
| typedef yarp::sig::FlexImage | FlexImage |
Protected Member Functions | |
| void | regenerate_rgb_image () |
| void | regenerate_depth_image () |
Protected Attributes | |
| FlexImage | m_rgbImage |
| depthImage | m_depthImage |
| bool | m_depth_mirror = false |
| bool | m_rgb_mirror = false |
| std::recursive_mutex | m_mutex |
Additional Inherited Members | |
| Public Types inherited from yarp::dev::IRGBDSensor | |
| enum | RGBDSensor_status { RGBD_SENSOR_NOT_READY = 0 , RGBD_SENSOR_OK_STANDBY = 1 , RGBD_SENSOR_OK_IN_USE = 2 , RGB_SENSOR_ERROR = 3 , DEPTH_SENSOR_ERROR = 4 , RGBD_SENSOR_GENERIC_ERROR = 5 , RGBD_SENSOR_TIMEOUT = 6 } |
| Public Attributes inherited from FakeDepthCameraDriver_ParamsParser | |
| const std::string | m_device_classname = {"FakeDepthCameraDriver"} |
| const std::string | m_device_name = {"fakeDepthCamera"} |
| bool | m_parser_is_strict = false |
| const parser_version_type | m_parser_version = {} |
| std::string | m_provided_configuration |
| const std::string | m_rgb_h_defaultValue = {"480.0"} |
| const std::string | m_rgb_w_defaultValue = {"640.0"} |
| const std::string | m_dep_h_defaultValue = {"480.0"} |
| const std::string | m_dep_w_defaultValue = {"640.0"} |
| const std::string | m_accuracy_defaultValue = {"0.001"} |
| const std::string | m_rgb_Vfov_defaultValue = {"50.0"} |
| const std::string | m_rgb_Hfov_defaultValue = {"36.0"} |
| const std::string | m_dep_Vfov_defaultValue = {"50.0"} |
| const std::string | m_dep_Hfov_defaultValue = {"36.0"} |
| const std::string | m_dep_near_defaultValue = {"0.2"} |
| const std::string | m_dep_far_defaultValue = {"6.0"} |
| const std::string | m_test_distance_constant_defaultValue = {"2.0"} |
| double | m_rgb_h = {480.0} |
| double | m_rgb_w = {640.0} |
| double | m_dep_h = {480.0} |
| double | m_dep_w = {640.0} |
| double | m_accuracy = {0.001} |
| double | m_rgb_Vfov = {50.0} |
| double | m_rgb_Hfov = {36.0} |
| double | m_dep_Vfov = {50.0} |
| double | m_dep_Hfov = {36.0} |
| double | m_dep_near = {0.2} |
| double | m_dep_far = {6.0} |
| double | m_test_distance_constant = {2.0} |
fakeDepthCamera_mini: Documentation to be added
Parameters required by this device are shown in class: FakeDepthCameraDriver_ParamsParser
Definition at line 34 of file FakeDepthCameraDriver_mini.h.
|
protected |
Definition at line 40 of file FakeDepthCameraDriver_mini.h.
|
protected |
Definition at line 43 of file FakeDepthCameraDriver_mini.h.
|
protected |
Definition at line 42 of file FakeDepthCameraDriver_mini.h.
|
protected |
Definition at line 41 of file FakeDepthCameraDriver_mini.h.
| FakeDepthCameraDriver_mini::FakeDepthCameraDriver_mini | ( | ) |
Definition at line 24 of file FakeDepthCameraDriver_mini.cpp.
|
overridedefault |
|
overridevirtual |
Close the DeviceDriver.
Reimplemented from yarp::dev::DeviceDriver.
Definition at line 40 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the minimum detectable variation in distance [meter].
| accuracy | will return the sensor resolution in meters. |
Implements yarp::dev::IDepthVisualParams.
Definition at line 243 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the clipping planes of the sensor.
| nearPlane | minimum distance at which the sensor start measuring. Object closer than this distance will not be detected. |
| farPlane | maximum distance beyond which the sensor stop measuring. Object farther than this distance will not be detected. |
Implements yarp::dev::IDepthVisualParams.
Definition at line 250 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the field of view (FOV) of the depth camera.
| horizontalFov | will return the value of the horizontal fov in degrees |
| verticalFov | will return the value of the vertical fov in degrees |
Implements yarp::dev::IDepthVisualParams.
Definition at line 213 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Return the height of each frame.
Implements yarp::dev::IDepthVisualParams.
Definition at line 201 of file FakeDepthCameraDriver_mini.cpp.
|
override |
Definition at line 303 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the intrinsic parameters of the depth camera.
| intrinsic | return a yarp::sig::IntrinsicParams containing intrinsic parameters of the optical model of the camera. |
Implements yarp::dev::IDepthVisualParams.
Definition at line 221 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the mirroring setting of the sensor.
| mirror | true if image is mirrored, false otherwise |
Implements yarp::dev::IDepthVisualParams.
Definition at line 266 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the resolution of the depth image from the camera.
| width | image width |
| height | image height |
Implements yarp::dev::IDepthVisualParams.
Definition at line 121 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Return the height of each frame.
Implements yarp::dev::IDepthVisualParams.
Definition at line 207 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the extrinsic parameters from the device.
| extrinsic | return a rototranslation matrix describing the position of the depth optical frame with respect to the rgb frame |
Implements yarp::dev::IRGBDSensor.
Definition at line 280 of file FakeDepthCameraDriver_mini.cpp.
|
override |
Definition at line 313 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Return an error message in case of error.
For debugging purpose and user notification. Error message will be reset after any successful command
| message | A string explaining the last error occurred. |
Implements yarp::dev::IRGBDSensor.
Definition at line 329 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the field of view (FOV) of the rgb camera.
| horizontalFov | will return the value of the horizontal fov in degrees |
| verticalFov | will return the value of the vertical fov in degrees |
Implements yarp::dev::IRgbVisualParams.
Definition at line 161 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Return the height of each frame.
Implements yarp::dev::IRgbVisualParams.
Definition at line 47 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the rgb frame from the device.
The pixel type of the source image will usually be set as a VOCAB_PIXEL_RGB, but the user can call the function with the pixel type of his/her choice. The conversion if possible, will be done automatically on client side (TO BO VERIFIED). Note: this will consume CPU power because it will not use GPU optimization. Use VOCAB_PIXEL_RGB for best performances.
| rgbImage | the image to be filled. |
| timeStamp | time in which the image was acquired. Optional, ignored if nullptr. |
Implements yarp::dev::IRGBDSensor.
Definition at line 293 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the intrinsic parameters of the rgb camera.
| intrinsic | return a yarp::sig::IntrinsicParams containing intrinsic parameters of the optical model of the camera. |
Implements yarp::dev::IRgbVisualParams.
Definition at line 183 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the mirroring setting of the sensor.
| mirror | true if image is mirrored, false otherwise |
Implements yarp::dev::IRgbVisualParams.
Definition at line 169 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the resolution of the rgb image from the camera.
| width | image width |
| height | image height |
Implements yarp::dev::IRgbVisualParams.
Definition at line 67 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Get the possible configurations of the camera.
| configurations | list of camera supported configurations as CameraConfig type |
Implements yarp::dev::IRgbVisualParams.
Definition at line 59 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Return the width of each frame.
Implements yarp::dev::IRgbVisualParams.
Definition at line 53 of file FakeDepthCameraDriver_mini.cpp.
|
override |
Definition at line 322 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Open the DeviceDriver.
| config | is a list of parameters for the device. Which parameters are effective for your device can vary. If there is no example for your device, you can run the "yarpdev" program with the verbose flag set to probe what parameters the device is checking. If that fails too, you'll need to read the source code (please nag one of the yarp developers to add documentation for your device). |
Reimplemented from yarp::dev::DeviceDriver.
Definition at line 30 of file FakeDepthCameraDriver_mini.cpp.
|
protected |
Definition at line 91 of file FakeDepthCameraDriver_mini.cpp.
|
protected |
Definition at line 75 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Set the minimum detectable variation in distance [meter] when possible.
| the | desired resolution in meters. |
Implements yarp::dev::IDepthVisualParams.
Definition at line 154 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Set the clipping planes of the sensor.
| nearPlane | minimum distance at which the sensor start measuring. Object closer than this distance will not be detected. |
| farPlane | maximum distance beyond which the sensor stop measuring. Object farther than this distance will not be detected. |
Implements yarp::dev::IDepthVisualParams.
Definition at line 258 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Set the field of view (FOV) of the depth camera.
| horizontalFov | will set the value of the horizontal fov in degrees |
| verticalFov | will set the value of the vertical fov in degrees |
Implements yarp::dev::IDepthVisualParams.
Definition at line 146 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Set the mirroring setting of the sensor.
| mirror | true if image should be mirrored, false otherwise |
Implements yarp::dev::IDepthVisualParams.
Definition at line 273 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Set the resolution of the depth image from the camera.
| width | image width |
| height | image height |
Implements yarp::dev::IDepthVisualParams.
Definition at line 129 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Set the field of view (FOV) of the rgb camera.
| horizontalFov | will set the value of the horizontal fov in degrees |
| verticalFov | will set the value of the vertical fov in degrees |
Implements yarp::dev::IRgbVisualParams.
Definition at line 138 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Set the mirroring setting of the sensor.
| mirror | true if image should be mirrored, false otherwise |
Implements yarp::dev::IRgbVisualParams.
Definition at line 176 of file FakeDepthCameraDriver_mini.cpp.
|
overridevirtual |
Set the resolution of the rgb image from the camera.
| width | image width |
| height | image height |
Implements yarp::dev::IRgbVisualParams.
Definition at line 112 of file FakeDepthCameraDriver_mini.cpp.
|
protected |
Definition at line 90 of file FakeDepthCameraDriver_mini.h.
|
protected |
Definition at line 89 of file FakeDepthCameraDriver_mini.h.
|
protected |
Definition at line 94 of file FakeDepthCameraDriver_mini.h.
|
protected |
Definition at line 91 of file FakeDepthCameraDriver_mini.h.
|
protected |
Definition at line 88 of file FakeDepthCameraDriver_mini.h.
 1.9.8