|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
Interface for a generic control board device implementing a PID controller. More...
#include <yarp/dev/IPidControl.h>
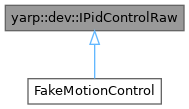
 Inheritance diagram for yarp::dev::IPidControlRaw:
Public Member Functions | |
| virtual | ~IPidControlRaw () |
| Destructor. | |
| virtual yarp::dev::ReturnValue | getAvailablePidsRaw (int j, std::vector< PidControlTypeEnum > &avail)=0 |
| Return a list of available pid types mode for the given joint. | |
| virtual yarp::dev::ReturnValue | setPidRaw (const PidControlTypeEnum &pidtype, int j, const Pid &pid)=0 |
| Set new PID value for a joint axis. | |
| virtual yarp::dev::ReturnValue | setPidsRaw (const PidControlTypeEnum &pidtype, const Pid *pids)=0 |
| Set new PID value on multiple axes. | |
| virtual yarp::dev::ReturnValue | setPidReferenceRaw (const PidControlTypeEnum &pidtype, int j, double ref)=0 |
| Set the controller reference for a given axis. | |
| virtual yarp::dev::ReturnValue | setPidReferencesRaw (const PidControlTypeEnum &pidtype, const double *refs)=0 |
| Set the controller reference, multiple axes. | |
| virtual yarp::dev::ReturnValue | setPidErrorLimitRaw (const PidControlTypeEnum &pidtype, int j, double limit)=0 |
| Set the error limit for the controller on a specific joint. | |
| virtual yarp::dev::ReturnValue | setPidErrorLimitsRaw (const PidControlTypeEnum &pidtype, const double *limits)=0 |
| Get the error limit for the controller on all joints. | |
| virtual yarp::dev::ReturnValue | getPidErrorRaw (const PidControlTypeEnum &pidtype, int j, double *err)=0 |
| Get the current error for a joint. | |
| virtual yarp::dev::ReturnValue | getPidErrorsRaw (const PidControlTypeEnum &pidtype, double *errs)=0 |
| Get the error of all joints. | |
| virtual yarp::dev::ReturnValue | getPidOutputRaw (const PidControlTypeEnum &pidtype, int j, double *out)=0 |
| Get the output of the controller (e.g. | |
| virtual yarp::dev::ReturnValue | getPidOutputsRaw (const PidControlTypeEnum &pidtype, double *outs)=0 |
| Get the output of the controllers (e.g. | |
| virtual yarp::dev::ReturnValue | getPidRaw (const PidControlTypeEnum &pidtype, int j, Pid *pid)=0 |
| Get current PID value for a specific joint. | |
| virtual yarp::dev::ReturnValue | getPidsRaw (const PidControlTypeEnum &pidtype, Pid *pids)=0 |
| Get current PID value for a specific joint. | |
| virtual yarp::dev::ReturnValue | getPidExtraInfoRaw (const PidControlTypeEnum &pidtype, int j, yarp::dev::PidExtraInfo &info)=0 |
| Get PID extra info and measurement units for a specific joint. | |
| virtual yarp::dev::ReturnValue | getPidExtraInfosRaw (const PidControlTypeEnum &pidtype, std::vector< yarp::dev::PidExtraInfo > &info)=0 |
| Get PID extra info and measurement units for a specific joint. | |
| virtual yarp::dev::ReturnValue | getPidReferenceRaw (const PidControlTypeEnum &pidtype, int j, double *ref)=0 |
| Get the current reference of the PID controller for a specific joint. | |
| virtual yarp::dev::ReturnValue | getPidReferencesRaw (const PidControlTypeEnum &pidtype, double *refs)=0 |
| Get the current reference of all PID controllers. | |
| virtual yarp::dev::ReturnValue | getPidErrorLimitRaw (const PidControlTypeEnum &pidtype, int j, double *limit)=0 |
| Get the error limit for the controller on a specific joint. | |
| virtual yarp::dev::ReturnValue | getPidErrorLimitsRaw (const PidControlTypeEnum &pidtype, double *limits)=0 |
| Get the error limit for all controllers. | |
| virtual yarp::dev::ReturnValue | resetPidRaw (const PidControlTypeEnum &pidtype, int j)=0 |
| Reset the controller of a given joint, usually sets the current status of the joint as the reference value for the PID, and resets the integrator. | |
| virtual yarp::dev::ReturnValue | disablePidRaw (const PidControlTypeEnum &pidtype, int j)=0 |
| Disable the PID computation for a joint. | |
| virtual yarp::dev::ReturnValue | enablePidRaw (const PidControlTypeEnum &pidtype, int j)=0 |
| Enable the PID computation for a joint. | |
| virtual yarp::dev::ReturnValue | setPidOffsetRaw (const PidControlTypeEnum &pidtype, int j, double v)=0 |
| Set an offset value for a given controller. | |
| virtual yarp::dev::ReturnValue | setPidFeedforwardRaw (const PidControlTypeEnum &pidtype, int j, double v)=0 |
| Set the feedforward value for the specified PID controller. | |
| virtual yarp::dev::ReturnValue | getPidOffsetRaw (const PidControlTypeEnum &pidtype, int j, double &v)=0 |
| Get the currently set offset value for the specified PID controller. | |
| virtual yarp::dev::ReturnValue | getPidFeedforwardRaw (const PidControlTypeEnum &pidtype, int j, double &v)=0 |
| Get the currently set feedforward value for the specified PID controller. | |
| virtual yarp::dev::ReturnValue | isPidEnabledRaw (const PidControlTypeEnum &pidtype, int j, bool &enabled)=0 |
| Get the current status (enabled/disabled) of the PID controller. | |
Interface for a generic control board device implementing a PID controller.
Definition at line 30 of file IPidControl.h.
|
inlinevirtual |
Destructor.
Definition at line 36 of file IPidControl.h.
|
pure virtual |
Disable the PID computation for a joint.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
Implemented in FakeMotionControl.
|
pure virtual |
Enable the PID computation for a joint.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
Implemented in FakeMotionControl.
|
pure virtual |
Return a list of available pid types mode for the given joint.
| j | joint number |
| avail | a vector that will contain the list of available control modes for joint j. |
Implemented in FakeMotionControl.
|
pure virtual |
Get the error limit for the controller on a specific joint.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| limit | pointer to storage |
Implemented in FakeMotionControl.
|
pure virtual |
Get the error limit for all controllers.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| limits | pointer to the array that will store the output |
Implemented in FakeMotionControl.
|
pure virtual |
Get the current error for a joint.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| err | pointer to the storage for the return value |
Implemented in FakeMotionControl.
|
pure virtual |
Get the error of all joints.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| errs | pointer to the vector that will store the errors |
Implemented in FakeMotionControl.
|
pure virtual |
Get PID extra info and measurement units for a specific joint.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| units | the measurement units for the specified PID. |
Implemented in FakeMotionControl.
|
pure virtual |
Get PID extra info and measurement units for a specific joint.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| units | vector that will store the info about of the pids. |
Implemented in FakeMotionControl.
|
pure virtual |
Get the currently set feedforward value for the specified PID controller.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| v | the feedforward value |
Implemented in FakeMotionControl.
|
pure virtual |
Get the currently set offset value for the specified PID controller.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| v | the offset value |
Implemented in FakeMotionControl.
|
pure virtual |
Get the output of the controller (e.g.
pwm value)
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| out | pointer to storage for return value |
Implemented in FakeMotionControl.
|
pure virtual |
Get the output of the controllers (e.g.
pwm value)
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| outs | pointer to the vector that will store the output values |
Implemented in FakeMotionControl.
|
pure virtual |
Get current PID value for a specific joint.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| pid | pointer to storage for the return value. |
Implemented in FakeMotionControl.
|
pure virtual |
Get the current reference of the PID controller for a specific joint.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| ref | pointer to storage for return value |
Implemented in FakeMotionControl.
|
pure virtual |
Get the current reference of all PID controllers.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| refs | vector that will store the output. |
Implemented in FakeMotionControl.
|
pure virtual |
Get current PID value for a specific joint.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| pids | vector that will store the values of the pids. |
Implemented in FakeMotionControl.
|
pure virtual |
Get the current status (enabled/disabled) of the PID controller.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| enabled | the current status of the PID controller. |
Implemented in FakeMotionControl.
|
pure virtual |
Reset the controller of a given joint, usually sets the current status of the joint as the reference value for the PID, and resets the integrator.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
Implemented in FakeMotionControl.
|
pure virtual |
Set the error limit for the controller on a specific joint.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| limit | limit value |
Implemented in FakeMotionControl.
|
pure virtual |
Get the error limit for the controller on all joints.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| limits | pointer to the vector with the new limits |
Implemented in FakeMotionControl.
|
pure virtual |
Set the feedforward value for the specified PID controller.
This value will be multiplied by the PID feedforward gain.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| v | the feedforward value |
Implemented in FakeMotionControl.
|
pure virtual |
Set an offset value for a given controller.
The value will added to the output of the PID controller
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| v | the offset value |
Implemented in FakeMotionControl.
|
pure virtual |
Set new PID value for a joint axis.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| pid | new PID value |
Implemented in FakeMotionControl.
|
pure virtual |
Set the controller reference for a given axis.
Warning this method can result in very large torques and should be used carefully. If you do not understand this warning you should avoid using this method. Have a look at other interfaces (e.g. position control).
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| j | joint number |
| ref | new reference point |
Implemented in FakeMotionControl.
|
pure virtual |
Set the controller reference, multiple axes.
Warning this method can result in very large torques and should be used carefully. If you do not understand this warning you should avoid using this method. Have a look at other interfaces (e.g. position control).
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| refs | pointer to the vector that contains the new reference points. |
Implemented in FakeMotionControl.
|
pure virtual |
Set new PID value on multiple axes.
| pidtype | the id of the PID that will be affected by the command (e.g. position, velocity etc) |
| pids | pointer to a vector of pids |
Implemented in FakeMotionControl.
 1.9.8