|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
fakeCalibrator: A fake calibrator implementation for testing purposes.
More...
#include <fake/fakeCalibrator/FakeCalibrator.h>
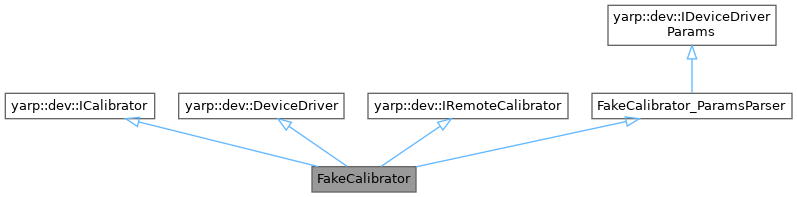
 Inheritance diagram for FakeCalibrator:
Public Member Functions | |
| FakeCalibrator () | |
| Default constructor. | |
| ~FakeCalibrator () | |
| Destructor. | |
| virtual bool | open (yarp::os::Searchable &config) override |
| Open the device driver. | |
| virtual bool | close () override |
| Close the device driver. | |
| yarp::dev::ReturnValue | calibrate (DeviceDriver *device) override |
| Calibrate method. | |
| yarp::dev::ReturnValue | park (DeviceDriver *dd, bool wait=true) override |
| yarp::dev::ReturnValue | quitPark () override |
| yarp::dev::ReturnValue | quitCalibrate () override |
| yarp::dev::IRemoteCalibrator * | getCalibratorDevice () override |
| getCalibratorDevice: return the pointer stored with the setCalibratorDevice | |
| yarp::dev::ReturnValue | calibrateSingleJoint (int j) override |
| calibrateSingleJoint: call the calibration procedure for the single joint | |
| yarp::dev::ReturnValue | calibrateWholePart () override |
| calibrateWholePart: call the procedure for calibrating the whole device | |
| yarp::dev::ReturnValue | homingSingleJoint (int j) override |
| homingSingleJoint: call the homing procedure for a single joint | |
| yarp::dev::ReturnValue | homingWholePart () override |
| homingWholePart: call the homing procedure for a the whole part/device | |
| yarp::dev::ReturnValue | parkSingleJoint (int j, bool _wait=true) override |
| parkSingleJoint(): start the parking procedure for the single joint | |
| yarp::dev::ReturnValue | parkWholePart () override |
| parkWholePart: start the parking procedure for the whole part | |
| Public Member Functions inherited from yarp::dev::ICalibrator | |
| virtual | ~ICalibrator ()=default |
| virtual yarp::dev::ReturnValue | calibrate (DeviceDriver *dd)=0 |
| virtual yarp::dev::ReturnValue | park (DeviceDriver *dd, bool wait=true)=0 |
| Public Member Functions inherited from yarp::dev::DeviceDriver | |
| DeviceDriver () | |
| DeviceDriver (const DeviceDriver &other)=delete | |
| DeviceDriver (DeviceDriver &&other) noexcept=delete | |
| DeviceDriver & | operator= (const DeviceDriver &other)=delete |
| DeviceDriver & | operator= (DeviceDriver &&other) noexcept=delete |
| virtual | ~DeviceDriver () |
| virtual std::string | id () const |
| Return the id assigned to the PolyDriver. | |
| virtual void | setId (const std::string &id) |
| Set the id for this device. | |
| template<class T > | |
| bool | view (T *&x) |
| Get an interface to the device driver. | |
| virtual DeviceDriver * | getImplementation () |
| Some drivers are bureaucrats, pointing at others. | |
| Public Member Functions inherited from yarp::dev::IRemoteCalibrator | |
| IRemoteCalibrator () | |
| This interface is meant to remotize the access of the calibration device in order to allow users to remotely call the calibration procedure for a single joint or the whole device and let the calibrator do the job. | |
| virtual | ~IRemoteCalibrator ()=default |
| virtual yarp::dev::ReturnValue | setCalibratorDevice (yarp::dev::IRemoteCalibrator *dev) |
| setCalibratorDevice: store the pointer to the calibrator device. | |
| virtual yarp::dev::ReturnValue | isCalibratorDevicePresent (bool *isCalib) |
| isCalibratorDevicePresent: check if a calibrator device has been set | |
| virtual yarp::dev::ReturnValue | releaseCalibratorDevice () |
| releaseCalibratorDevice: reset the internal pointer to NULL when stop using the calibrator | |
| Public Member Functions inherited from FakeCalibrator_ParamsParser | |
| FakeCalibrator_ParamsParser () | |
| ~FakeCalibrator_ParamsParser () override=default | |
| bool | parseParams (const yarp::os::Searchable &config) override |
| Parse the DeviceDriver parameters. | |
| std::string | getDeviceClassName () const override |
| Get the name of the DeviceDriver class. | |
| std::string | getDeviceName () const override |
| Get the name of the device (i.e. | |
| std::string | getDocumentationOfDeviceParams () const override |
| Get the documentation of the DeviceDriver's parameters. | |
| std::vector< std::string > | getListOfParams () const override |
| Return a list of all params used by the device. | |
| bool | getParamValue (const std::string ¶mName, std::string ¶mValue) const override |
| Return the value (represented as a string) of the requested parameter. | |
| std::string | getConfiguration () const override |
| Return the configuration of the device. | |
| Public Member Functions inherited from yarp::dev::IDeviceDriverParams | |
| virtual | ~IDeviceDriverParams () |
Additional Inherited Members | |
| Public Attributes inherited from FakeCalibrator_ParamsParser | |
| const std::string | m_device_classname = {"FakeCalibrator"} |
| const std::string | m_device_name = {"fakeCalibrator"} |
| bool | m_parser_is_strict = false |
| const parser_version_type | m_parser_version = {} |
| std::string | m_provided_configuration |
| const std::string | m_param1_defaultValue = {"0.0"} |
| double | m_param1 = {0.0} |
fakeCalibrator: A fake calibrator implementation for testing purposes.
Parameters required by this device are shown in class: FakeCalibrator_ParamsParser
Definition at line 22 of file FakeCalibrator.h.
| FakeCalibrator::FakeCalibrator | ( | ) |
Default constructor.
Definition at line 20 of file FakeCalibrator.cpp.
| FakeCalibrator::~FakeCalibrator | ( | ) |
Destructor.
Definition at line 24 of file FakeCalibrator.cpp.
|
override |
Calibrate method.
Call this to calibrate the complete device.
| dd | is a pointer to the DeviceDriver to calibrate which must implement the position control interfaces of the standard control board devices. |
Definition at line 41 of file FakeCalibrator.cpp.
|
overridevirtual |
calibrateSingleJoint: call the calibration procedure for the single joint
| j | joint to be calibrated |
Implements yarp::dev::IRemoteCalibrator.
Definition at line 100 of file FakeCalibrator.cpp.
|
overridevirtual |
calibrateWholePart: call the procedure for calibrating the whole device
Implements yarp::dev::IRemoteCalibrator.
Definition at line 112 of file FakeCalibrator.cpp.
|
overridevirtual |
Close the device driver.
Reimplemented from yarp::dev::DeviceDriver.
Definition at line 35 of file FakeCalibrator.cpp.
|
overridevirtual |
getCalibratorDevice: return the pointer stored with the setCalibratorDevice
Reimplemented from yarp::dev::IRemoteCalibrator.
Definition at line 95 of file FakeCalibrator.cpp.
|
overridevirtual |
homingSingleJoint: call the homing procedure for a single joint
| j | joint to be calibrated |
Implements yarp::dev::IRemoteCalibrator.
Definition at line 118 of file FakeCalibrator.cpp.
|
overridevirtual |
homingWholePart: call the homing procedure for a the whole part/device
Implements yarp::dev::IRemoteCalibrator.
Definition at line 124 of file FakeCalibrator.cpp.
|
overridevirtual |
Open the device driver.
| config | is a reference to a Searchable object which contains the initialization parameters. |
Reimplemented from yarp::dev::DeviceDriver.
Definition at line 30 of file FakeCalibrator.cpp.
|
override |
Definition at line 74 of file FakeCalibrator.cpp.
|
overridevirtual |
parkSingleJoint(): start the parking procedure for the single joint
Implements yarp::dev::IRemoteCalibrator.
Definition at line 130 of file FakeCalibrator.cpp.
|
overridevirtual |
parkWholePart: start the parking procedure for the whole part
Implements yarp::dev::IRemoteCalibrator.
Definition at line 137 of file FakeCalibrator.cpp.
|
overridevirtual |
Implements yarp::dev::ICalibrator.
Definition at line 85 of file FakeCalibrator.cpp.
|
overridevirtual |
Implements yarp::dev::ICalibrator.
Definition at line 90 of file FakeCalibrator.cpp.
 1.9.8