|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
#include <messages/ISimulatedWorldMsgs/idl_generated_code/ISimulatedWorldMsgs.h>
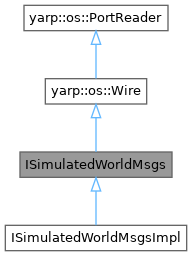
 Inheritance diagram for ISimulatedWorldMsgs:
Public Member Functions | |
| virtual yarp::os::ApplicationNetworkProtocolVersion | getLocalProtocolVersion () |
| virtual yarp::os::ApplicationNetworkProtocolVersion | getRemoteProtocolVersion () |
| virtual bool | checkProtocolVersion () |
| ISimulatedWorldMsgs () | |
| virtual yarp::dev::ReturnValue | makeSphere (const std::string &id_name, const double radius, const yarp::sig::Pose6D &pose, const yarp::sig::ColorRGB &color, const std::string &frame_name, const bool gravity_enable, const bool collision_enable) |
| virtual yarp::dev::ReturnValue | makeBox (const std::string &id_name, const double width, const double height, const double thickness, const yarp::sig::Pose6D &pose, const yarp::sig::ColorRGB &color, const std::string &frame_name, const bool gravity_enable, const bool collision_enable) |
| virtual yarp::dev::ReturnValue | makeCylinder (const std::string &id_name, const double radius, const double length, const yarp::sig::Pose6D &pose, const yarp::sig::ColorRGB &color, const std::string &frame_name, const bool gravity_enable, const bool collision_enable) |
| virtual yarp::dev::ReturnValue | makeFrame (const std::string &id_name, const double size, const yarp::sig::Pose6D &pose, const yarp::sig::ColorRGB &color, const std::string &frame_name, const bool gravity_enable, const bool collision_enable) |
| virtual yarp::dev::ReturnValue | makeModel (const std::string &id_name, const std::string &filename, const yarp::sig::Pose6D &pose, const std::string &frame_name, const bool gravity_enable, const bool collision_enable) |
| virtual yarp::dev::ReturnValue | makeActor (const std::string &id_name, const std::string &skinfile, const std::string &animfile, const yarp::sig::Pose6D &pose) |
| virtual yarp::dev::ReturnValue | changeColor (const std::string &id, const yarp::sig::ColorRGB &color) |
| virtual yarp::dev::ReturnValue | setPose (const std::string &id, const yarp::sig::Pose6D &pose, const std::string &frame_name) |
| virtual yarp::dev::ReturnValue | enableGravity (const std::string &id, const bool enable) |
| virtual yarp::dev::ReturnValue | enableCollision (const std::string &id, const bool enable) |
| virtual getPoseReturnValue | getPose (const std::string &id, const std::string &frame_name) |
| virtual yarp::dev::ReturnValue | deleteObject (const std::string &id) |
| virtual yarp::dev::ReturnValue | deleteAll () |
| virtual getListReturnValue | getList () |
| virtual yarp::dev::ReturnValue | attach (const std::string &id, const std::string &link_name) |
| virtual yarp::dev::ReturnValue | detach (const std::string &id) |
| virtual yarp::dev::ReturnValue | rename (const std::string &old_name, const std::string &new_name) |
| virtual std::vector< std::string > | help (const std::string &functionName="--all") |
| bool | read (yarp::os::ConnectionReader &connection) override |
| Read this object from a network connection. | |
| Public Member Functions inherited from yarp::os::Wire | |
| yarp::os::WireLink & | yarp () |
| Get YARP state associated with this object. | |
| const yarp::os::WireLink & | yarp () const |
| Get YARP state associated with this object (const version). | |
| Public Member Functions inherited from yarp::os::PortReader | |
| virtual | ~PortReader () |
| Destructor. | |
| virtual Type | getReadType () const |
Definition at line 24 of file ISimulatedWorldMsgs.h.
| ISimulatedWorldMsgs::ISimulatedWorldMsgs | ( | ) |
Definition at line 4216 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4371 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4281 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Definition at line 81 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4346 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4336 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4381 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4311 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4301 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4356 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Definition at line 96 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4321 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Definition at line 66 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Definition at line 4402 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4271 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4231 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4241 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4251 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4261 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4221 of file ISimulatedWorldMsgs.cpp.
|
overridevirtual |
Read this object from a network connection.
Override this for your particular class.
| reader | an interface to the network connection for reading |
Implements yarp::os::PortReader.
Definition at line 4492 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4391 of file ISimulatedWorldMsgs.cpp.
|
virtual |
Reimplemented in ISimulatedWorldMsgsImpl.
Definition at line 4291 of file ISimulatedWorldMsgs.cpp.
 1.9.8