|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
Control board, encoder interface. More...
#include <yarp/dev/IMotorEncoders.h>
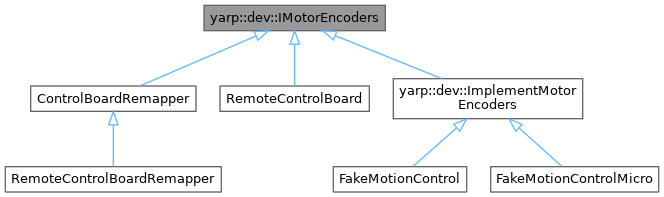
 Inheritance diagram for yarp::dev::IMotorEncoders:
Public Member Functions | |
| virtual | ~IMotorEncoders () |
| Destructor. | |
| virtual yarp::dev::ReturnValue | getNumberOfMotorEncoders (int *num)=0 |
| Get the number of available motor encoders. | |
| virtual yarp::dev::ReturnValue | resetMotorEncoder (int m)=0 |
| Reset motor encoder, single motor. | |
| virtual yarp::dev::ReturnValue | resetMotorEncoders ()=0 |
| Reset motor encoders. | |
| virtual yarp::dev::ReturnValue | setMotorEncoderCountsPerRevolution (int m, const double cpr)=0 |
| Sets number of counts per revolution for motor encoder m. | |
| virtual yarp::dev::ReturnValue | getMotorEncoderCountsPerRevolution (int m, double *cpr)=0 |
| Gets number of counts per revolution for motor encoder m. | |
| virtual yarp::dev::ReturnValue | setMotorEncoder (int m, const double val)=0 |
| Set the value of the motor encoder for a given motor. | |
| virtual yarp::dev::ReturnValue | setMotorEncoders (const double *vals)=0 |
| Set the value of all motor encoders. | |
| virtual yarp::dev::ReturnValue | getMotorEncoder (int m, double *v)=0 |
| Read the value of a motor encoder. | |
| virtual yarp::dev::ReturnValue | getMotorEncoders (double *encs)=0 |
| Read the position of all motor encoders. | |
| virtual yarp::dev::ReturnValue | getMotorEncodersTimed (double *encs, double *time)=0 |
| Read the instantaneous position of all motor encoders. | |
| virtual yarp::dev::ReturnValue | getMotorEncoderTimed (int m, double *encs, double *time)=0 |
| Read the instantaneous position of a motor encoder. | |
| virtual yarp::dev::ReturnValue | getMotorEncoderSpeed (int m, double *sp)=0 |
| Read the instantaneous speed of a motor encoder. | |
| virtual yarp::dev::ReturnValue | getMotorEncoderSpeeds (double *spds)=0 |
| Read the instantaneous speed of all motor encoders. | |
| virtual yarp::dev::ReturnValue | getMotorEncoderAcceleration (int m, double *acc)=0 |
| Read the instantaneous acceleration of a motor encoder. | |
| virtual yarp::dev::ReturnValue | getMotorEncoderAccelerations (double *accs)=0 |
| Read the instantaneous acceleration of all motor encoders. | |
Control board, encoder interface.
Definition at line 150 of file IMotorEncoders.h.
|
inlinevirtual |
Destructor.
Definition at line 156 of file IMotorEncoders.h.
|
pure virtual |
Read the value of a motor encoder.
| m | motor encoder number |
| v | pointer to storage for the return value |
Implemented in ControlBoard_nwc_yarp, yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Read the instantaneous acceleration of a motor encoder.
| m | motor number |
| acc | pointer to the array that will contain the output |
Implemented in ControlBoard_nwc_yarp, yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Read the instantaneous acceleration of all motor encoders.
| accs | pointer to the array that will contain the output |
Implemented in yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, ControlBoard_nwc_yarp, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Gets number of counts per revolution for motor encoder m.
| m | motor number |
| cpr | vals pointer to the new value |
Implemented in yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, ControlBoard_nwc_yarp, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Read the position of all motor encoders.
| encs | pointer to the array that will contain the output |
Implemented in yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, ControlBoard_nwc_yarp, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Read the instantaneous speed of a motor encoder.
| m | motor number |
| sp | pointer to storage for the output |
Implemented in ControlBoard_nwc_yarp, yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Read the instantaneous speed of all motor encoders.
| spds | pointer to storage for the output values |
Implemented in yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, ControlBoard_nwc_yarp, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Read the instantaneous position of all motor encoders.
| encs | pointer to the array that will contain the output |
| time | pointer to the array that will contain individual timestamps |
Implemented in yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, yarp::dev::ImplementMotorEncoders, and ControlBoard_nwc_yarp.
|
pure virtual |
Read the instantaneous position of a motor encoder.
| m | motor index |
| encs | encoder value (pointer to) |
| time | corresponding timestamp (pointer to) |
Implemented in ControlBoard_nwc_yarp, yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Get the number of available motor encoders.
| m | pointer to a value representing the number of available motor encoders. |
Implemented in yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, ControlBoard_nwc_yarp, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Reset motor encoder, single motor.
Set the encoder value to zero.
| m | motor number |
Implemented in ControlBoard_nwc_yarp, yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Reset motor encoders.
Set the motor encoders value to zero.
Implemented in yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, ControlBoard_nwc_yarp, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Set the value of the motor encoder for a given motor.
| m | motor number |
| val | new value |
Implemented in ControlBoard_nwc_yarp, yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Sets number of counts per revolution for motor encoder m.
| m | motor number |
| cpr | new value |
Implemented in yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, ControlBoard_nwc_yarp, and yarp::dev::ImplementMotorEncoders.
|
pure virtual |
Set the value of all motor encoders.
| vals | pointer to the new values |
Implemented in yarp::dev::xHandControlBoard, ControlBoardRemappingEngine, ControlBoard_nwc_yarp, and yarp::dev::ImplementMotorEncoders.
 1.9.8